CREATE
  • Technology
    • BIOTECH
    • COMMUNICATIONS
    • COMPUTING
    • IMAGING
    • MATERIALS
    • ROBOTICS
    • SOFTWARE
  • Industry
    • DEFENCE
    • INFRASTRUCTURE
    • INNOVATION
    • MANUFACTURING
    • POLICY
    • PROJECTS
    • TRANSPORT
  • Sustainability
    • ENERGY
    • ENVIRONMENT
    • RESOURCES
  • Community
    • CULTURE
    • PEOPLE
  • Career
    • EDUCATION
    • INSPIRATION
    • LEADERSHIP
    • TRENDS
  • About
    • CONTACT
    • SUBSCRIBE
No Result
View All Result
CREATE
  • Technology
    • BIOTECH
    • COMMUNICATIONS
    • COMPUTING
    • IMAGING
    • MATERIALS
    • ROBOTICS
    • SOFTWARE
  • Industry
    • DEFENCE
    • INFRASTRUCTURE
    • INNOVATION
    • MANUFACTURING
    • POLICY
    • PROJECTS
    • TRANSPORT
  • Sustainability
    • ENERGY
    • ENVIRONMENT
    • RESOURCES
  • Community
    • CULTURE
    • PEOPLE
  • Career
    • EDUCATION
    • INSPIRATION
    • LEADERSHIP
    • TRENDS
  • About
    • CONTACT
    • SUBSCRIBE
No Result
View All Result
CREATE
No Result
View All Result
Home Technology Robotics

Are machine swarms the future of robotics?

Jonathan Bradley by Jonathan Bradley
25 August 2026
in Robotics, Features
Reading Time: 13 mins read
0
Are machine swarms the future of robotics?

Image: Getty

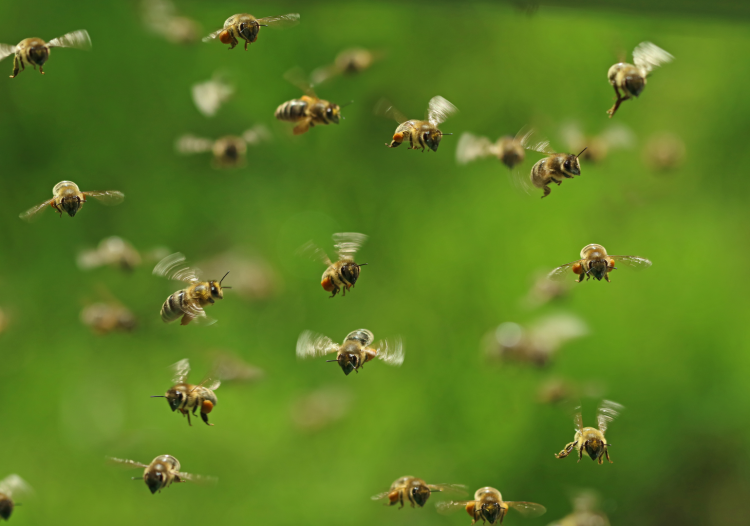
In nature, swarm intelligence is the result of many actors that produce a collective intent greater than any individual part. Can distributed decision-making show robotics engineers how to work with nature rather than against it?

The brain of an ant weighs 0.1 mg, with about 250,000 neurons packed into that space. It’s not a lot – a honey bee or cockroach brain packs four times the computational power – and, accordingly, individual ants are not the most sophisticated of thinkers.

Colonies of ants, however, can overcome their species’ intellectual shortfall to perform ingenious acts of problem-solving and coordination. They do this with no form of central control. There are no formic engineers or project directors sketching blueprints or designing CAD drawings for the colony to follow.

“Ant colonies work through a network of very simple local interactions; most ants can’t see and they operate by smell,” is how Stanford University’s Professor Deborah Gordon explained the process in a podcast produced by the university. “An ant colony is like a [human] brain in that there’s no central control. So just as no neuron tells the other neurons what to do, so no ant tells the other ants what to do.”

Traditionally, robotics has followed neither the path of human nor ant intelligence. Roboticists program systems to adhere to centralised controls and carefully coordinated interactions.

Roboticist and computer systems engineer Dr Kirstin Hagelskjaer Petersen, however, prefers to draw her ideas from termites – along with other swarms in the natural world, such as bees and social amoebae. Sometimes, she admits, she and her Cornell University team will watch nature documentaries for inspiration, wondering what might happen if they applied a wondrous biological technique to their own field.
Dr Kirstin Hagelskjaer Petersen, Cornell University

Swarm robotics, the often biologically inspired effort to harness collective intelligence in artificial systems, is the focus of Petersen’s research. She draws a distinction between her efforts to produce advanced autonomy in groups of independent robots and the more commonly found instances of multi-agent systems, consisting of centrally controlled robotic teams acting in parallel.

“When we say swarm robotics, it has a very different feel,” she said. “We’re talking about emergent complexity. They’re all locally interacting, so you can’t predict exactly what will emerge. Instead, you rely on statistical guarantees about a swarm’s behaviour. The benefit is that the system is far more versatile.”

That adaptability is part of the appeal of swarm robotics. Another is cost: one expensive robot is useless if it breaks, but it matters less if a swarm loses a few of its many machines.

“To support deployment of many robots, every single one has to be cheaper and less capable, but on the bright side, you have a tonne of redundancy,” Petersen said. 

“You have graceful degradation. You can adapt to circumstances, cover larger spaces and manipulate things that you wouldn’t be able to do with just a single point of contact. If you’re smart about the way you write your algorithms, it’s much more scalable.”

READ: 5 Australian autonomous systems already in service

Robots that do less

In their purest form, the machines produced by swarm roboticists look markedly different to traditional robots. Petersen’s most recent research involves a system she calls a “cross-link collective”, which comprises dozens of 200 mm winged modules consisting of little more than a motor, some sensors and a printed circuit board.

The modules form one of just two shapes: an I or a U. Alone, each is useless, but operating together – weak Velcro patches at the end of each wing allow them to connect and disconnect from one another – the robots form a mass that moves around obstacles like a fluid.

“Normally in modular robotic systems. or any robotic system, you carefully engineer everything,” Petersen said. “You decide how everything is fitted together, where the sensors and actuators go, and what signals flow between them.

“Here, we throw a bunch of these robots out there, and they continuously self-organise into reasonably functional units.”
“You can cover larger spaces. You can manipulate things that you wouldn’t be able to do with just a single point of contact. And if you’re smart about the way you write your algorithms, it’s much more scalable.”
Dr Kirstin Hagelskjaer Petersen, Cornell University

Each module performs just one motion, inspired by the Purcell swimmer, a physics model describing locomotion at microscopic scales.

“These chains form which are inherently optimised for speed and low torque, so they use very little energy. These properties emerged on their own because we gave up one of engineering’s most fundamental disciplines: designing exactly how everything fits together.

“The result is a powerful example of embodied intelligence: complex behaviour emerging not from sophisticated software but from the physical interaction of many simple components.”

Watching Petersen’s cross-link collective navigate a maze is an awe-inspiring and unsettling experience – the individual modules look both alive and unnatural, helpless and determined – but they don’t seem to have any immediate practical application.

Petersen sees swarm robotics as an exercise in engineering minimalism: finding the simplest combination of robots, behaviours and interactions that can accomplish a task.

“Yes, termites achieve more as a colony, but each individual termite is already an extraordinarily capable system,” she said. “Similarly, we can always build out our systems with more computation and control. The question is how much we can achieve before we need to.”

READ: Rise of the robots

Robotic agriculture

There are domains in which swarm robotics is beginning to find headway, Petersen said, pointing to war, entertainment and warehouses. She also highlights the potential for swarm robotics to be deployed in agriculture as a way of addressing labour shortages.

“That’s an obvious place where robotics can contribute. There are excellent researchers and engineers in agricultural robotics in Australia.”


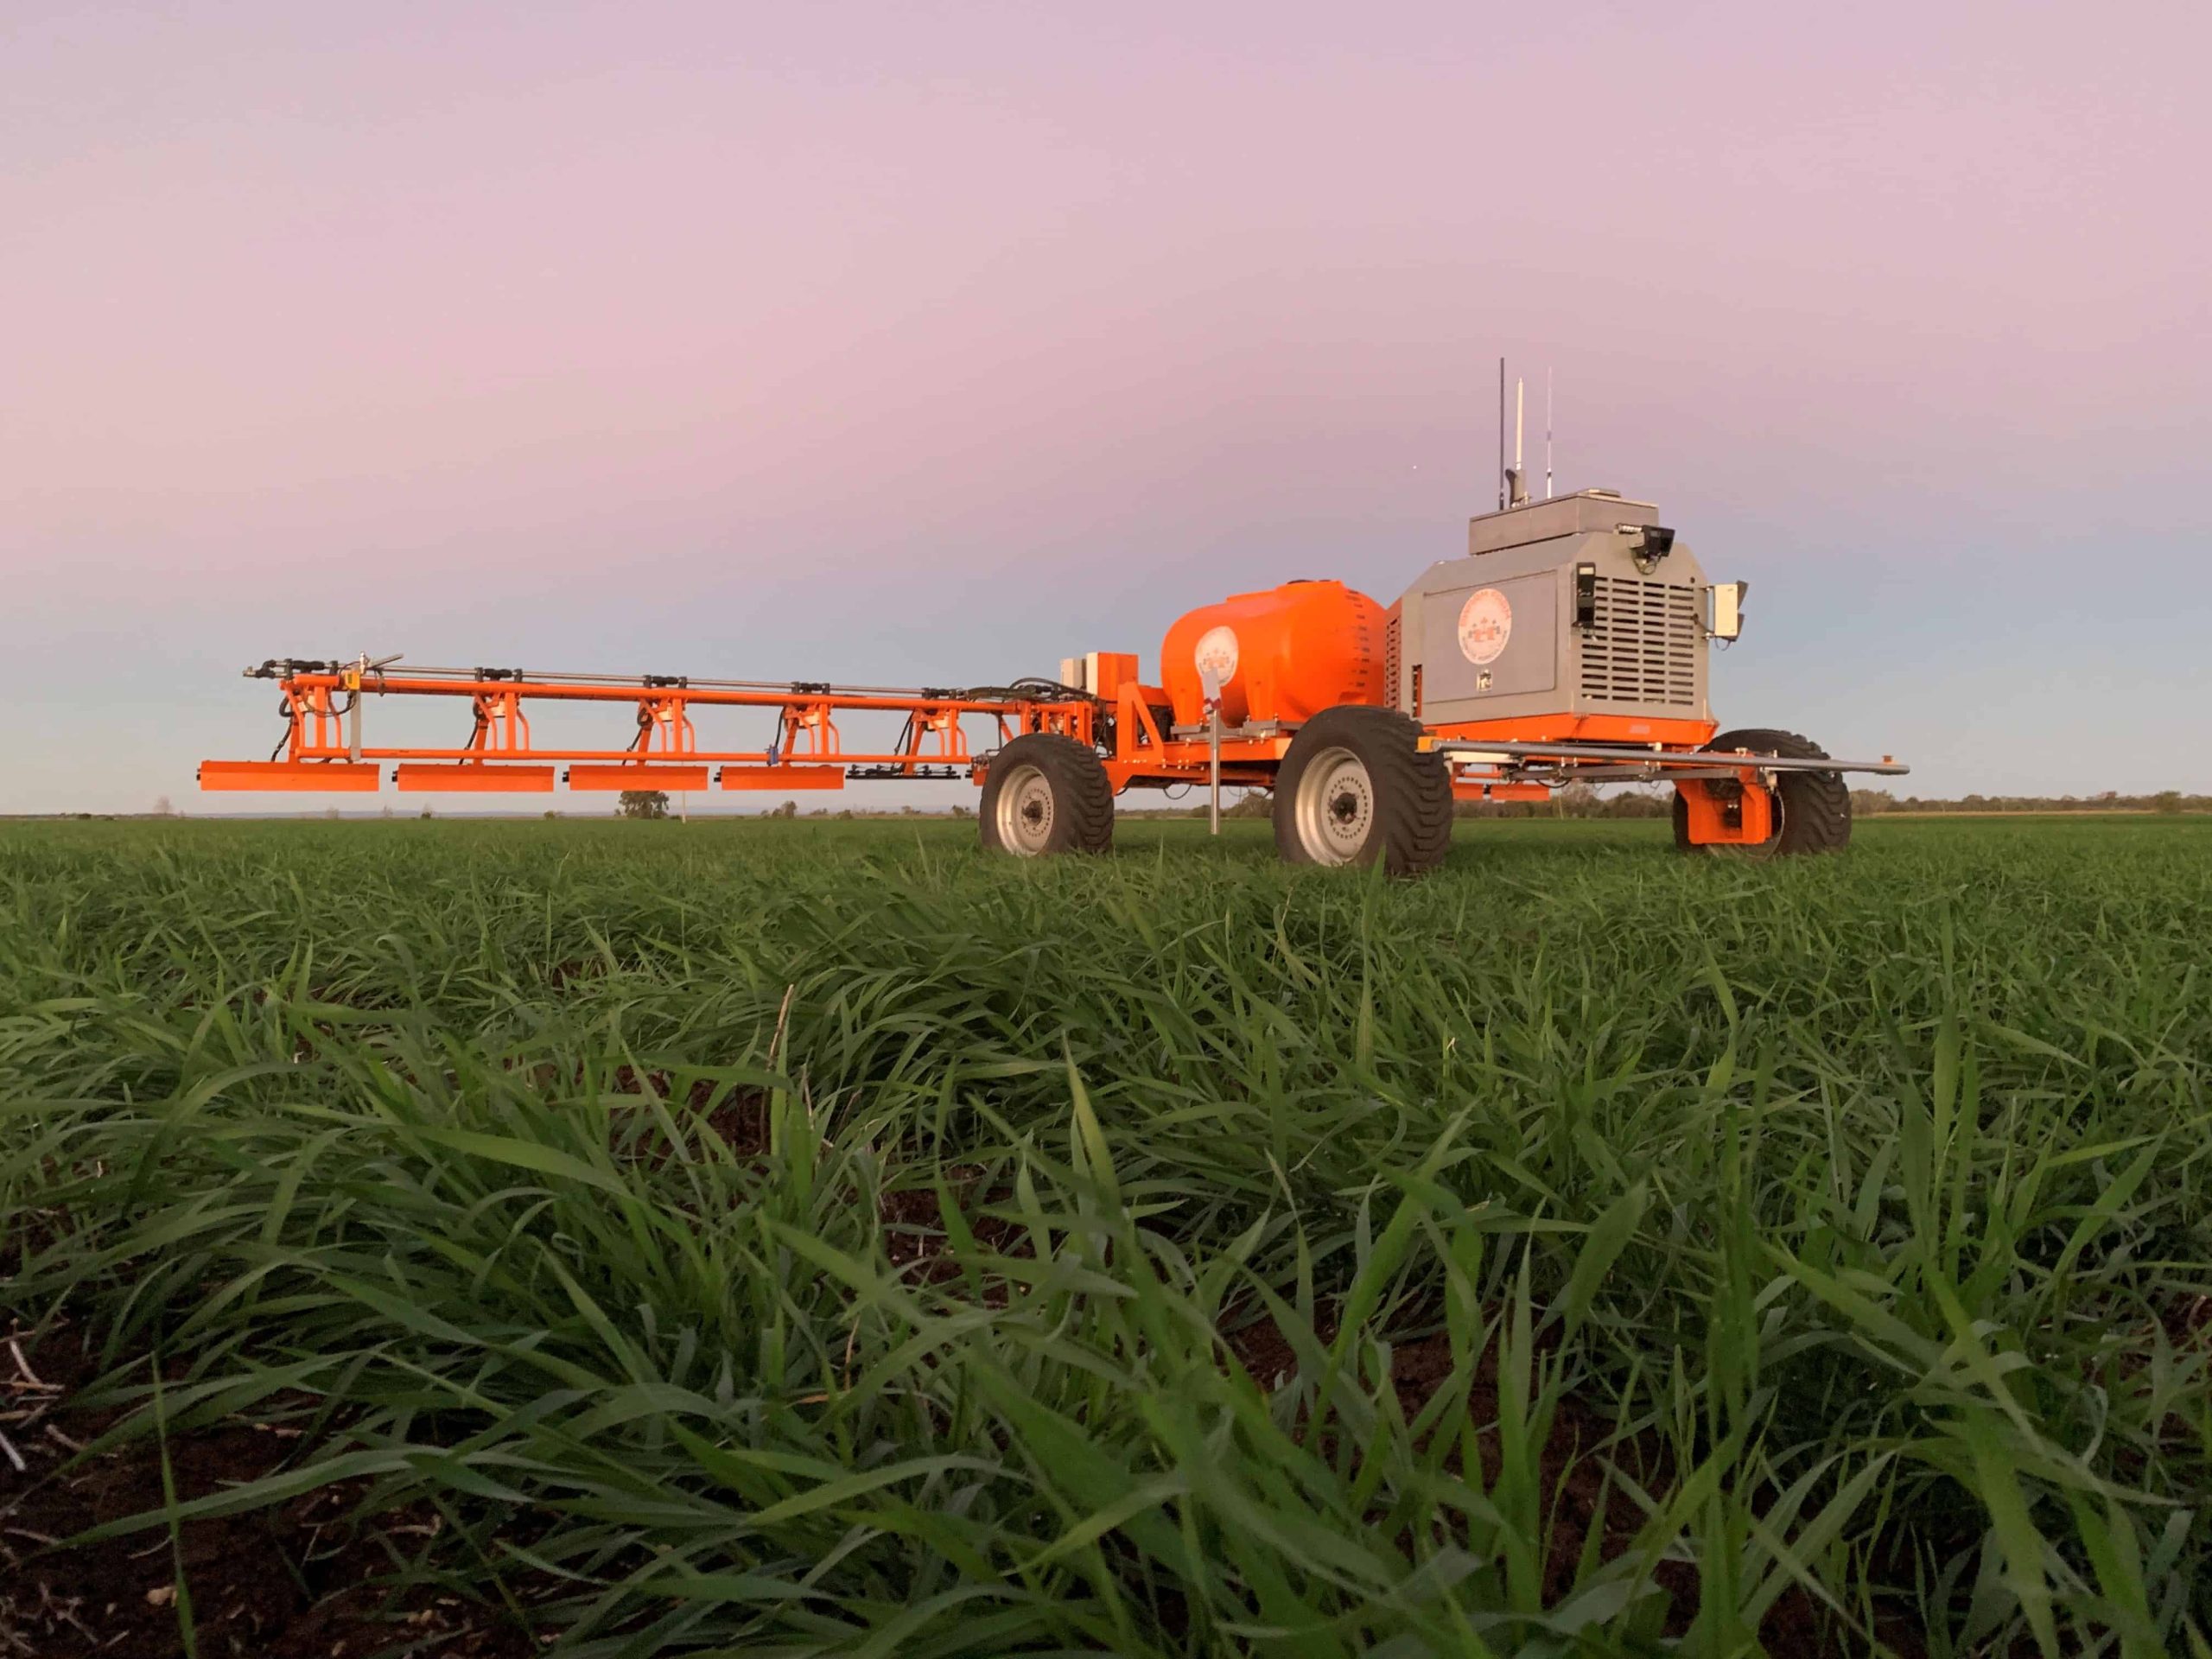
Queensland-based company SwarmFarm is at the forefront of this effort. Tom Holcombe, the company’s portfolio manager for Western Australia, said the company aims not to automate current processes, but to use technology to grow better crops.

“We use smaller, lighter, more precise machines going slower through the paddock, if we have to, to ultimately make the best decision for what’s required on the ground,” he said.

“If it has to come down to making a decision on a plant-by-plant basis, then we can potentially do that.”

Rather than spraying an entire field, one of the robots deployed might be used to target pesticides at a precise location, for instance, or to pull out a specific weed.

“Eventually we’ll use multiple smaller, lighter-weight machines to be able to achieve what we’re doing currently with one big machine,” Holcombe said.

The actual level of autonomy delivered by SwarmFarm’s technology varies. Holcombe notes that some farmers want greater control than others. And while they might trust a robot fleet to spray pesticide in the correct location, then return to restock with more chemicals before going back to the field, major events such as seeding could require more oversight.

SwarmFarm’s “Juliet” swarmbot. (Image: SwarmFarm)

“I think it comes back to who you ask and what they’re trying to achieve with autonomy,” he said. “Ultimately, you can go and throw sensors at something, but at the same time, you’ve got to make sure it’s reliable and make sure it actually works and can deliver the result that people are after.”

Introducing that autonomy to its machines and building trust with customers is the first step SwarmFarm is taking to eventually implementing genuine distributed decision-making.

“We know that to be successful with smaller machines, a change in the farming system is required,” Holcombe said.

READ: Swarm bodies: why drone fleets are the future of firefighting

Control centre

Practical application of swarm principles, then, demands a trade-off between the simplicity of each individual robot and its capacity to actually perform its desired task.

Another trade-off, according to CSIRO senior research scientist Dr Nicholas Lawrance, is in the level of centralised control an operator retains over a swarm.

“When you have a really large number of robots, it gets very hard to have centralised control,” he said. “If you only have a handful of robots, you can often just have one computer that’s making all the decisions, and it acts like one robot. It just decides and then it sends them to wherever they need to go. If you’ve got thousands, that becomes much harder.”
Dr Nicholas Lawrance, CSIRO

The compromise is to allow each robot in the swarm to have its own limited intelligence so it can make small decisions related to its immediate environment.

“They’re making their own decisions, and they have to agree locally on some kind of consensus,” he said. “It shares information maybe with its neighbours, and then you get the team to do what you want without a centralised controller saying, ‘You do this, you do that.’”

Doing the careful work of deploying robots to gather data in complex and uncertain environments means Lawrance is not willing to give control of his machines completely over to a decentralised swarm. Nevertheless, he understands the advantage of having a larger number of robots able to act autonomously.

“It’s about having the scale to collect data in a way that you either couldn’t before because it was inaccessible, or at a time rate or a spatial rate that you couldn’t [before],” he said. 

“Sometimes we have robots with different types of sensors and they complement each other. That’s where it makes sense, because you can choose which sensor goes to which place and they can coordinate.”
“Sometimes we have robots with different types of sensors and they complement each other. That’s where it makes sense, because you can choose which sensor goes to which place and they can coordinate.”
Dr Nicholas Lawrance, CSIRO

Lawrance’s robotic teams have the potential to work with marine scientists to collect data to monitor such phenomena as algal blooms. Since it’s expensive to take environmental DNA samples that can detect specific species, his robots could coordinate between devices that look for areas of potential interest and more specialised machines that gather precise measurements.

The uncertainty of the environment the robotic teams are entering is a key challenge that requires surrendering some decision-making authority to the squad.

“Getting the robot out into this environment is often a significant challenge,” Lawrance said. 

“They have limited range and some amount of autonomy, but they can’t deal with every single case. So you are trying to put them in places where you know roughly what to expect.”

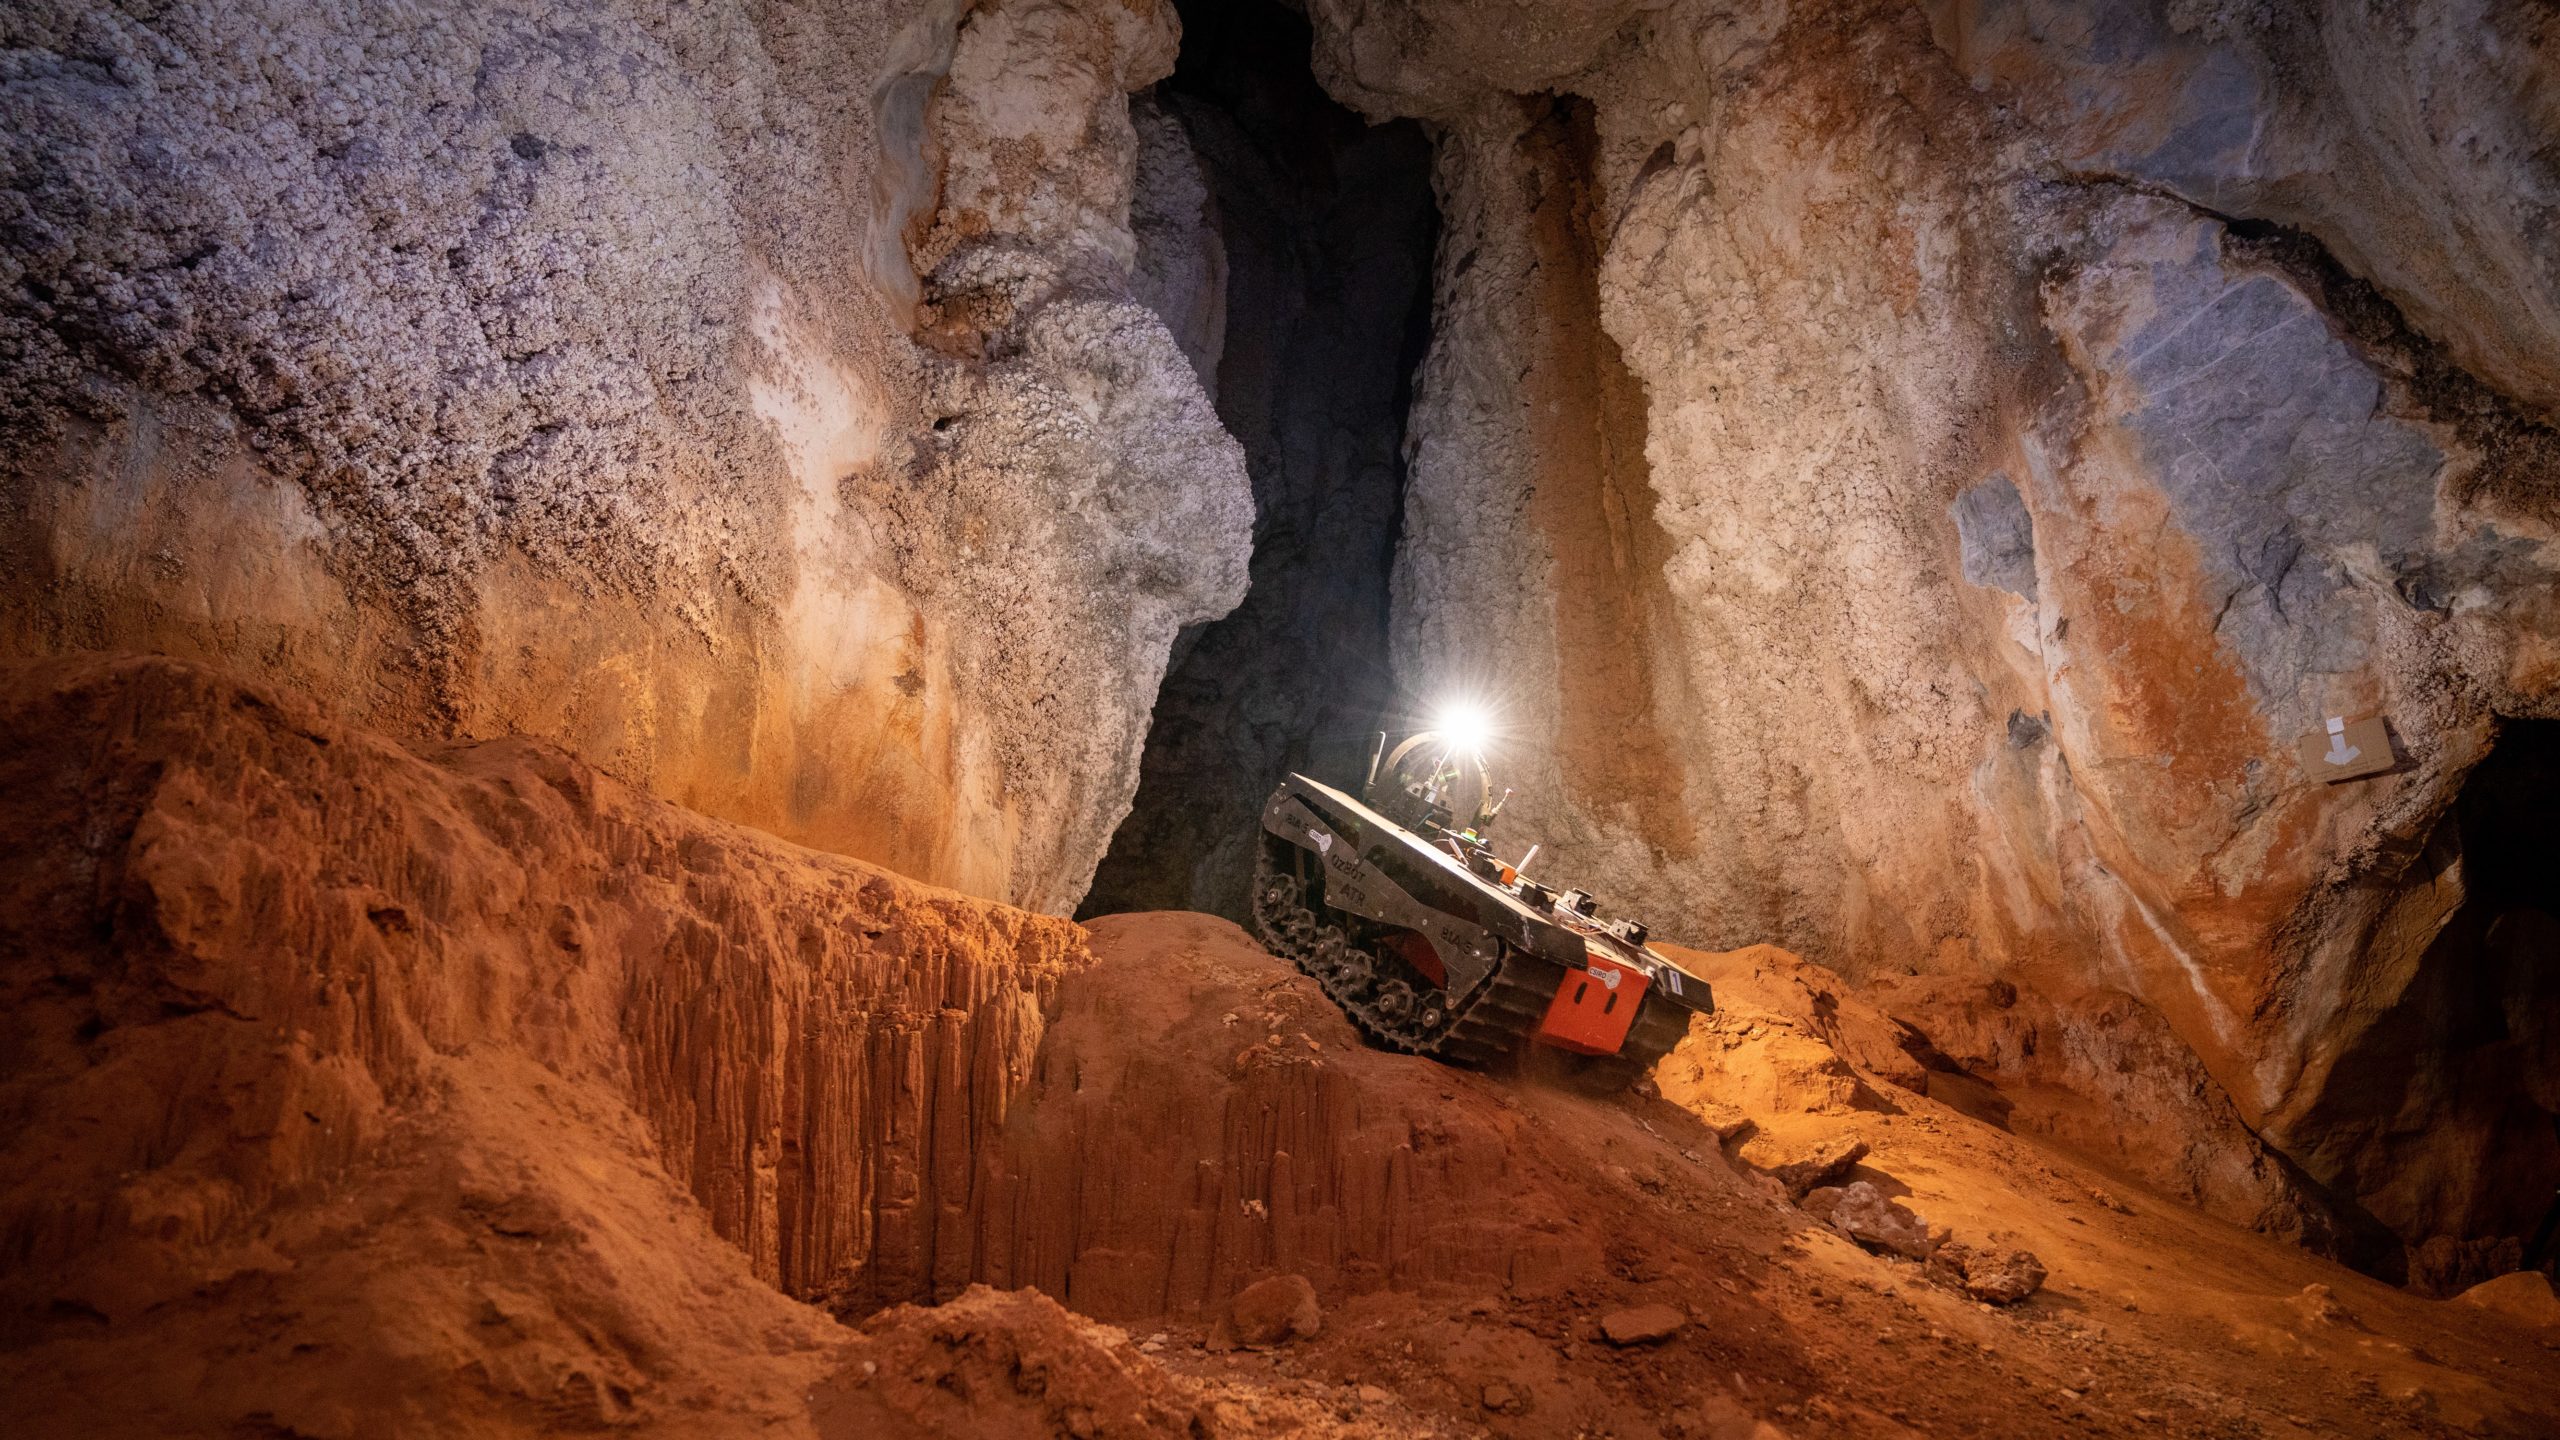
An autonomous robot during CSIRO’s DARPA Challenge. (Image: CSIRO)

Clemson University Professor Fatemeh Afghah also uses swarm robots – in her case, drones – for disaster management, including for firefighting. She highlights communication as one of the most significant challenges when working with multiple agents.

“When the swarm lead is down for any reason – if the communication is intermittent or if the agent is physically damaged – then who’s going to take over that task, or how are we going to redistribute the task between the agents?” she asked. 

“We can program the drones to operate independently, but the reason we have these drones on the fleet is actually to collect real-time data for the mission planner and the emergency control system.

“We don’t want these drones to just collect data and save it on an SD card. We want that data to be communicated in real time to a human to have a better understanding of what’s going on in the field.”

READ: Australian robotics team built for Olympics success

The trust factor

There remains a distinct gap between pure swarm intelligence, such as Petersen’s experimental cross-link collective, and the practical, on-the-ground applications being explored by engineers such as Lawrance and Afghah. Indeed, Lawrance has observed that too much autonomy can make the operators he works with nervous.

“We always assume that of course you want the most autonomy, because that’s what we do and that’s what we think people want,” he said.

“When you talk to stakeholders, they’re usually coming at it from a different angle. They’re already doing some part of this job, and they want to do it better or faster. Usually, they’re not interested in changing everything completely because they don’t trust it yet.”
Professor Fatemeh Afghah, Clemson University

Nonetheless, Afghah sees other domains where the technology can prove valuable.

“Disaster management, traffic management in urban areas, military applications,” she said. “Any complex system with critical restrictions in terms of timing – swarm intelligence could be a good player there.”

Petersen adds that the biomedical industry is one domain hoping to make use of swarm robots, creating microscopic devices that can be injected into the body to gather data or deliver drugs.

“It works really well because every robot is just so tiny and limited in power and sensors and compute, so you really do need a swarm to be able to do anything,” she said. “It hasn’t happened yet, but it’s certainly an area a lot of people are working on, and it’s hopefully imminent.” 

READ: Rethink Robotics revisited: A look back at the collaborative robots pioneer

Drones down

Sydney’s Vivid Festival this year planned a wondrous addition to the spectacle of lights: a thousand-strong swarm of colourful drones that would fill the sky with spectacular choreographed patterns. But after 83 of the drones unexpectedly plunged from the sky into Sydney Harbour, the remaining shows were cancelled.

Sydney’s Vivid festival. (Image: Getty)

This is not the first time an Australian aerial light display has ended in such disastrous fashion. A July 2023 show in Melbourne, preceding a World Cup game played by the Australian women’s soccer team, saw 427 of the swarm’s 500 drones fall into the Yarra River.

It’s a stark example of how collective intelligence can lead to collective failure, and prompted an inquiry by the Australian Transport Safety Bureau (ATSB).

It found that excessive windspeed caused the failure, with a unique combination of human, technical and design errors at play.

Michael Dawes, who led the ATSB investigation, told create a number of factors were involved:

  • The pilot was operating in a high-pressure environment.
  • The copilot had limited experience.
  • The crew did not launch a weather drone before the show to check conditions.
  • While the drone software did measure windspeed, it didn’t clearly communicate to the pilot that conditions were unsuitable for flying.

Since the light show failure, the manufacturer has updated the software to improve the pilot interface.

“You end up with these things building on each other,” Dawes said. “We have the heightened workload that was created through a number of different things, and we have the addition of the operational pressure, and so the way those two compound one another [affects] the launch decision.”

WATCH: New homegrown robotics lab promises to spearhead AI innovation

Swarm intelligence in nature

For many species in the natural world, swarm intelligence is a deeply ingrained survival strategy that goes beyond simple herding behaviour. Operating collaboratively enables creatures to behave with a sophistication and purpose beyond any individual member of the collective.

Here are some of nature’s most impressive swarm accomplishments:

Fish defence

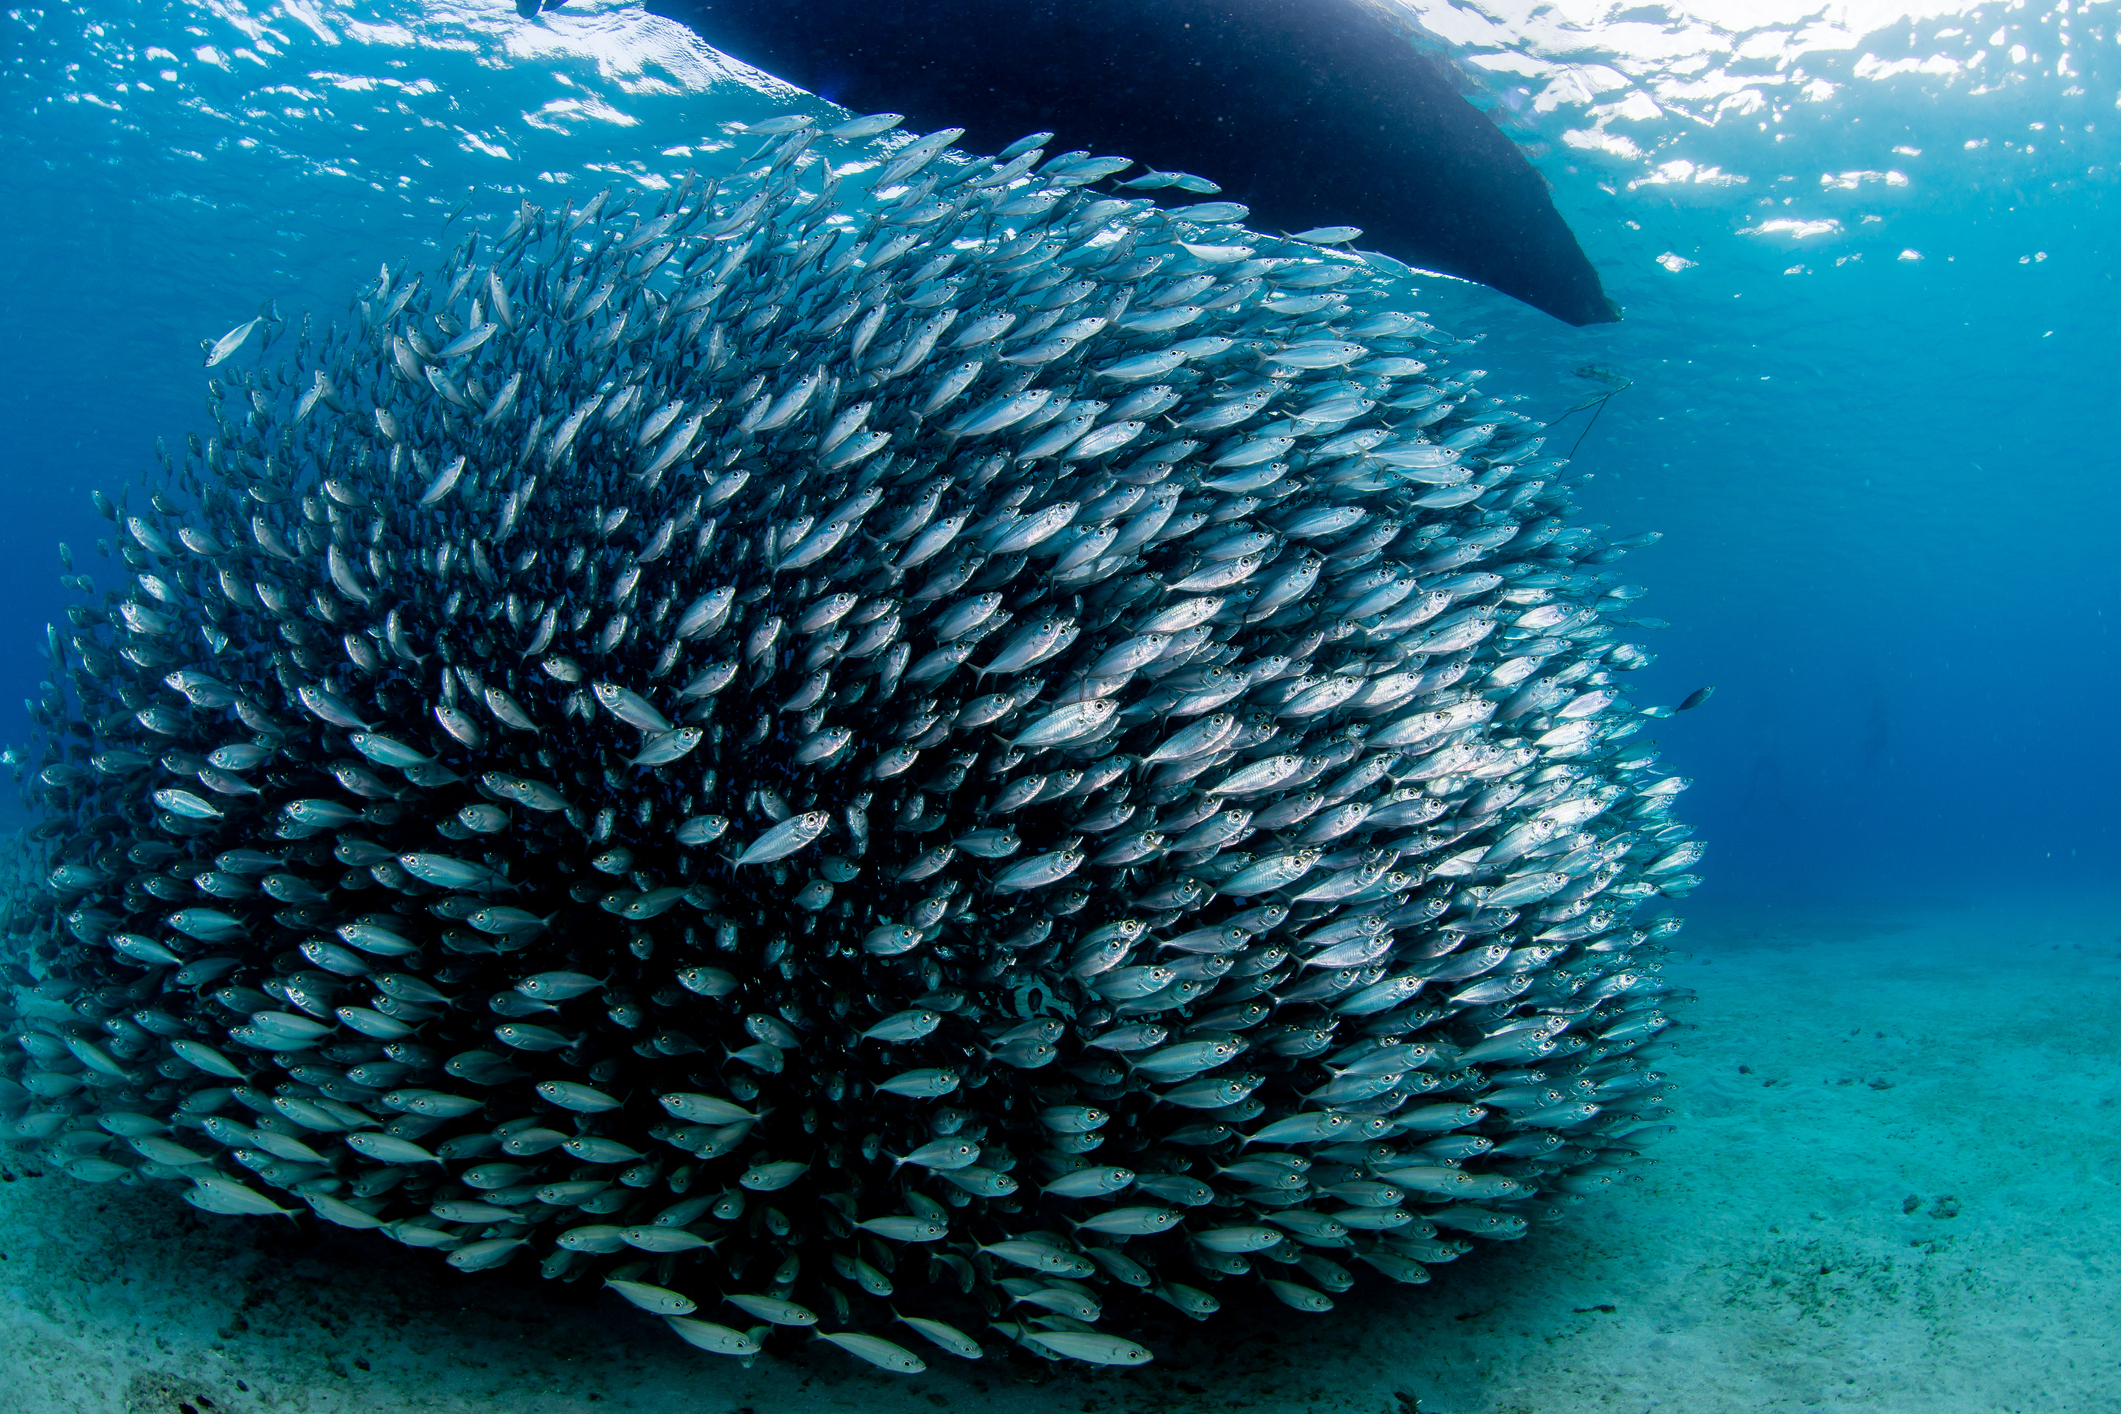
Small fish such as sardines defend against predators by packing themselves into a tightly constructed “bait ball”, which makes it difficult for individual fish to be identified and picked off. If necessary, the ball can disband, sending fish in all directions, before coming back together again.

Fish forming a “bait ball” as a defence mechanism. (Image: Getty)

Ant problem-solving 

One study, from the Weizmann Institute of Science, found that ants, working collaboratively to manoeuvre an object through a tight gap, can outperform humans under certain conditions.

Honey bee architecture

Bees can adjust the angle, size and shape of individual honeycomb components to construct a hive that adapts to constrained spaces and obstacles.

Termite construction 

Interaction between individual termites and their environment allows them to create mental maps of their mounds, allowing them to undertake repairs where needed.

Sheep and sheepdogs

Sheep might not seem the most sophisticated of thinkers, alone or en masse, but swarm roboticists are using them as models for systems that see simple agents governed by a handful of smarter “sheepdogs”.

Register now for the Information, Telecommunications and Electronics Engineering Symposium, held 19 November in Melbourne

Tags: agriculturebiomimicrydronesroboticsbushfiresswarms
Previous Post

“Build once, build right”: Developing Brisbane’s Olympic site for the long term

Next Post

How smart glasses technology could aid visually impaired people

Jonathan Bradley

Jonathan Bradley

Jonathan Bradley is a staff writer whose work has appeared in The Sydney Morning Herald, The Age, ABC News, SBS and Billboard. As well as engineering, he likes to write about politics, pop music, culture and cartoons.

Related Posts

The hidden microplastics risk in “green” plastic
Materials

The hidden microplastics risk in “green” plastic

3 September 2026
Push it to the limit: engineering Australia’s hypersonic aircraft
Features

Push it to the limit: engineering Australia’s hypersonic aircraft

3 September 2026
Seeing the good for the trees
Features

Seeing the good for the trees

3 September 2026
Next Post
How smart glasses technology could aid visually impaired people

How smart glasses technology could aid visually impaired people

Leave a Reply Cancel reply

Your email address will not be published. Required fields are marked *

create is brought to you by Engineers Australia, Australia's national body for engineers and the voice of more than 120,000 members. Backing today's problem-solvers so they can shape a better tomorrow.
  • ABOUT US
  • CONTACT US
  • SITEMAP
  • PRIVACY POLICY
  • TERMS
  • SUBSCRIBE

© 2024 Engineers Australia

No Result
View All Result
  • Technology
    • BIOTECH
    • COMMUNICATIONS
    • COMPUTING
    • IMAGING
    • MATERIALS
    • ROBOTICS
    • SOFTWARE
  • Industry
    • DEFENCE
    • INFRASTRUCTURE
    • INNOVATION
    • MANUFACTURING
    • POLICY
    • PROJECTS
    • TRANSPORT
  • Sustainability
    • ENERGY
    • ENVIRONMENT
    • RESOURCES
  • Community
    • CULTURE
    • PEOPLE
  • Career
    • EDUCATION
    • INSPIRATION
    • LEADERSHIP
    • TRENDS
  • About
    • CONTACT
    • SUBSCRIBE