
From Nobel Prize-winning origins to modern shopping centre carparks, speed humps cause extreme passenger discomfort. But it doesn’t have to be this way. Engineer Geoff Walton MIEAust conducted a kinematic analysis to break down the forces behind the bump and makes the scientific case for updating Australian standards.
The speed hump was first devised in 1953 by American physicist Arthur Compton, who introduced the installations while Chancellor of St Louis’s Washington University to thwart motorists speeding through campus. It was an extra-curricular activity for Compton, whose research into X-rays saw him share the 1927 Nobel Prize in Physics with the UK’s Charles Wilson.
Speed humps work by impeding the progress of a vehicle, and motorists tend not to appreciate having their progress impeded. Although these “slow” – or “Type 2” speed humps, prevalent in carparks and shopping centres, are irksome and cause discomfort to car occupants, they generally conform to the AS/NZS 2890.1:2004 standards, and when confronted with complaints, suppliers point to this compliance.
Using good engineering principles and science, the following analysis looks at how the standard could be amended to minimise the discomfort of passengers and motorists. The basis of this study is the mathematical equations and philosophy of kinematics, a branch of both applied and pure mathematics that considers how things are moving, not why they are moving.
The standard approach
In Australia, speed humps are covered by two standards. While each has its own specific area of application, their principles are applicable to any sort of road surface imperfection, such as raised street platforms, dropped or protruding inspection pit covers, gutters or potholes.
The AS/NZS 2890.1–2004 standard for off-street car-parking says, “where positive speed control is necessary with in a carpark, road humps as specified below shall be used,” and specifies two types of hump:
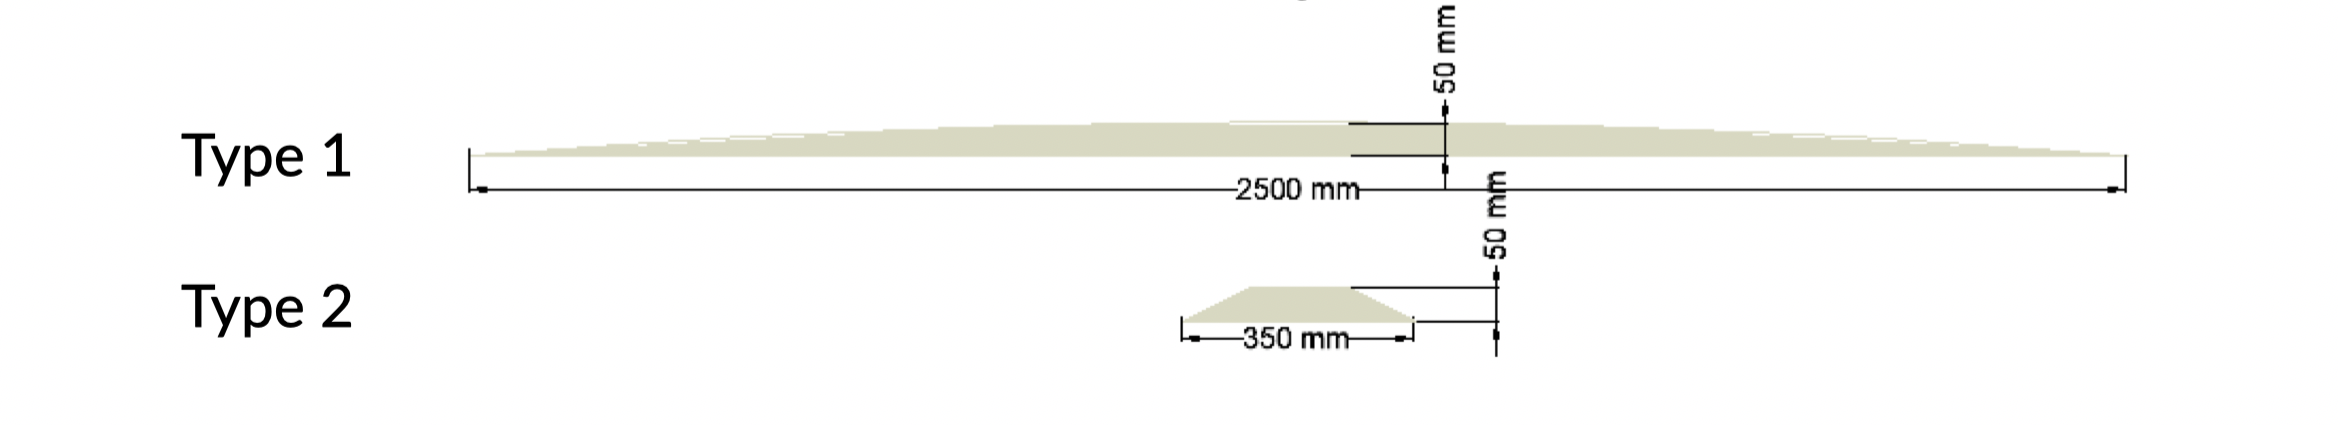
While types one and two are both available commercially, private carparks always opt for the cheaper Type 2 version, since it requires less material and less space.
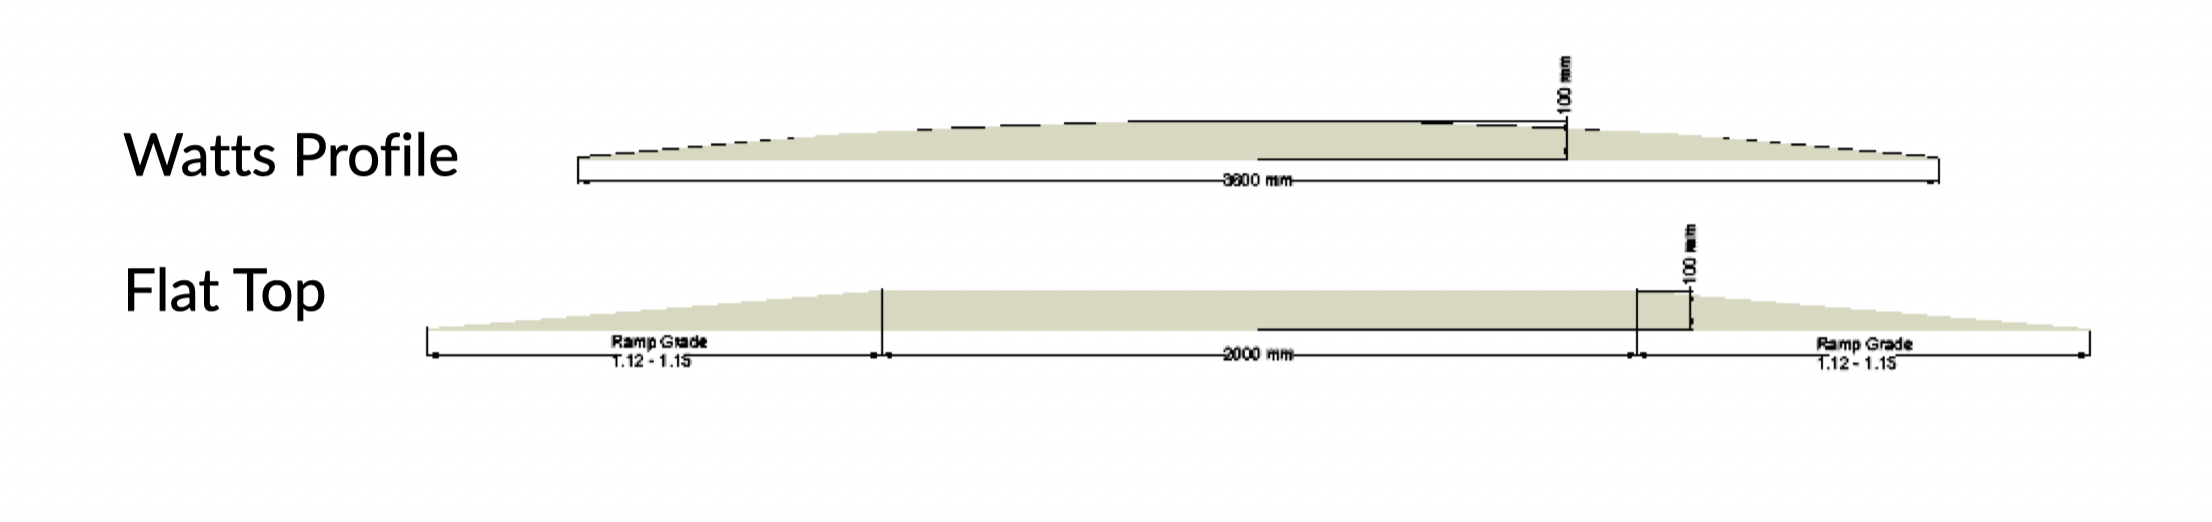
The AS 1742.13-2009 – Local Area Traffic Management standard, a collegial standard, says, “the function of a road hump is to reduce vehicle speeds by causing occupant discomfort when the hump is traversed at a speed above its design speed”.
It also specifies two humps:
READ: The case for designing bridges that last
Not too comfortable
For a vehicle occupant travelling over a speed hump, there’s a fine line between comfort and discomfort. The Australian Standards covering humps offer little guidance on this question. In 2020, however, Austroads published research report AP-R642-20, which reviewed seven Victorian and four New Zealand sites to evaluate “the design and performance of existing [raised street platform] treatments”.
This report was a major break-through in hump research, as it linked the four main parameters for humps design: ramp slope, height, speed, and comfort or discomfort. It related human comfort to measured accelerations, producing a summary graph of the results. While there was wide variation, the statistical best-fit trend line helps assess the relative importance of hump design parameters.
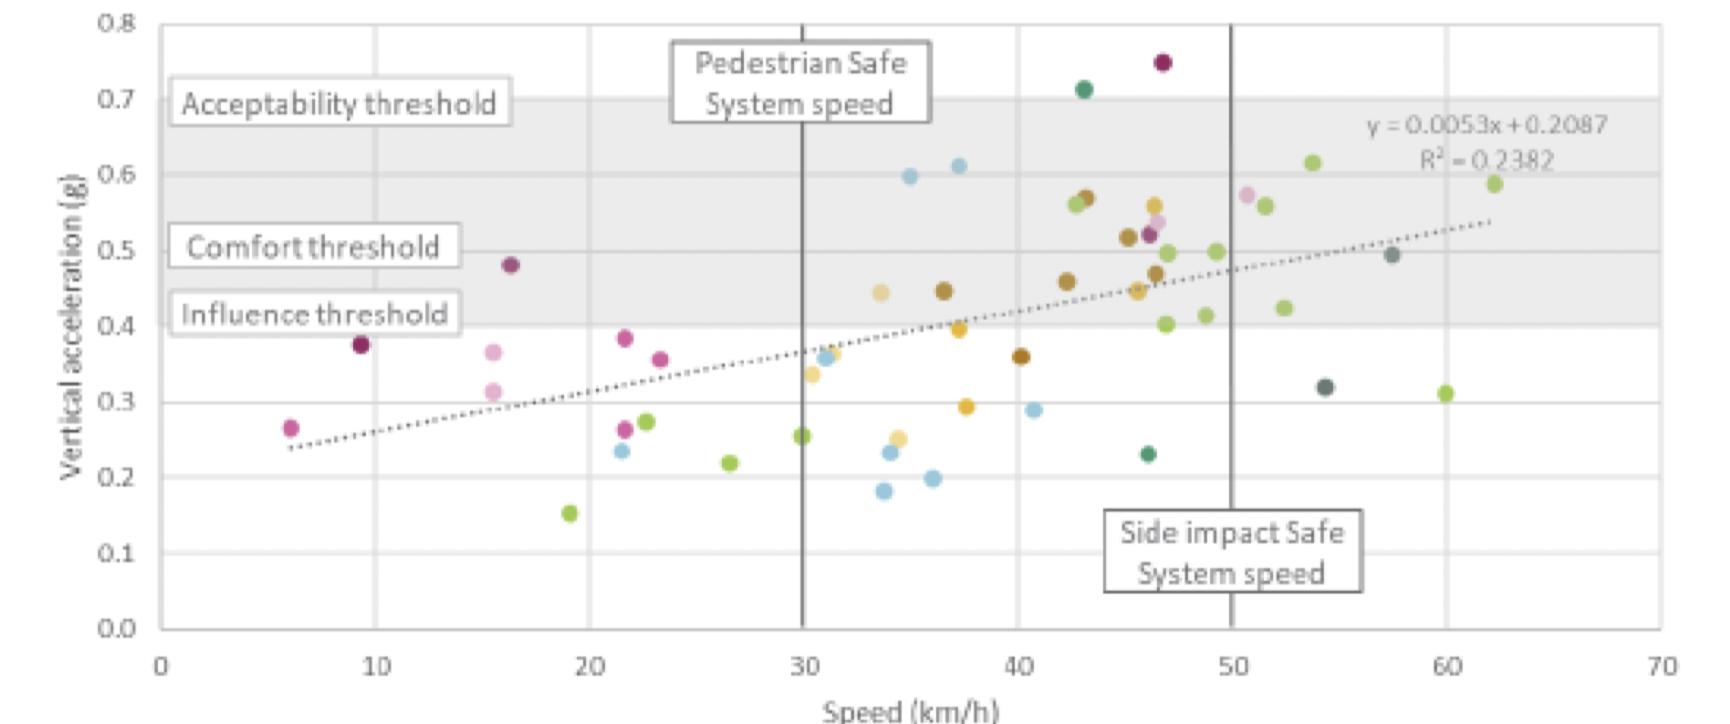
The Austroads researchers proposed that a range 0.4 to 0.7 g would be effective in curbing speed, depending on other factors present. For this study, I have adopted the lower 0.4 g as the desirable target for hump design using kinematic methods.
Kinematics is seen as a branch of both applied and pure mathematics, as it can be studied without considering the mass of a body or the forces acting upon it. Algebraically, it interacts with the motion parameters of acceleration, “a”; speed or velocity, “V”; and distance or displacement, “x”; and duration over time, “t”; under conditions of uniform or constant acceleration. Examples of constant acceleration abound in reality, from falling apples from trees (gravity) or rockets being launched, to the accelerating and braking of a motor car. In fact, there are few motions for which constant acceleration cannot be applied.
Kinematics has evolved from just two basic tenets:
- Newton’s second law of motion, where force is equal to the change in momentum (mV) per change in time.
Force = mass x velocity/time
or F = m x a
Note: If mass = 1, force = acceleration, correlating with Ampere’s idea of how, not why, objects move.
- The “mean speed theorem” or Merton Rule, developed by Merton College scholars at Oxford University in the 1300s, which has become known as the Merton Rule, where:
Average Velocity = 0.5 x (initial velocity + final velocity)
or vavg = 0.5 ( Vi + Vf )
The Merton Rule is straightforward today, but its application is extraordinarily crucial to moder-day analyses of all constant acceleration motions. Kinematics would not exist without it.
The kinematic equations
From the above two tenets, kinematics has four equations that link the four basic parameters of a, V, x and t. With them, any one of the basic parameters can be calculated from their other three.
These four equations are:
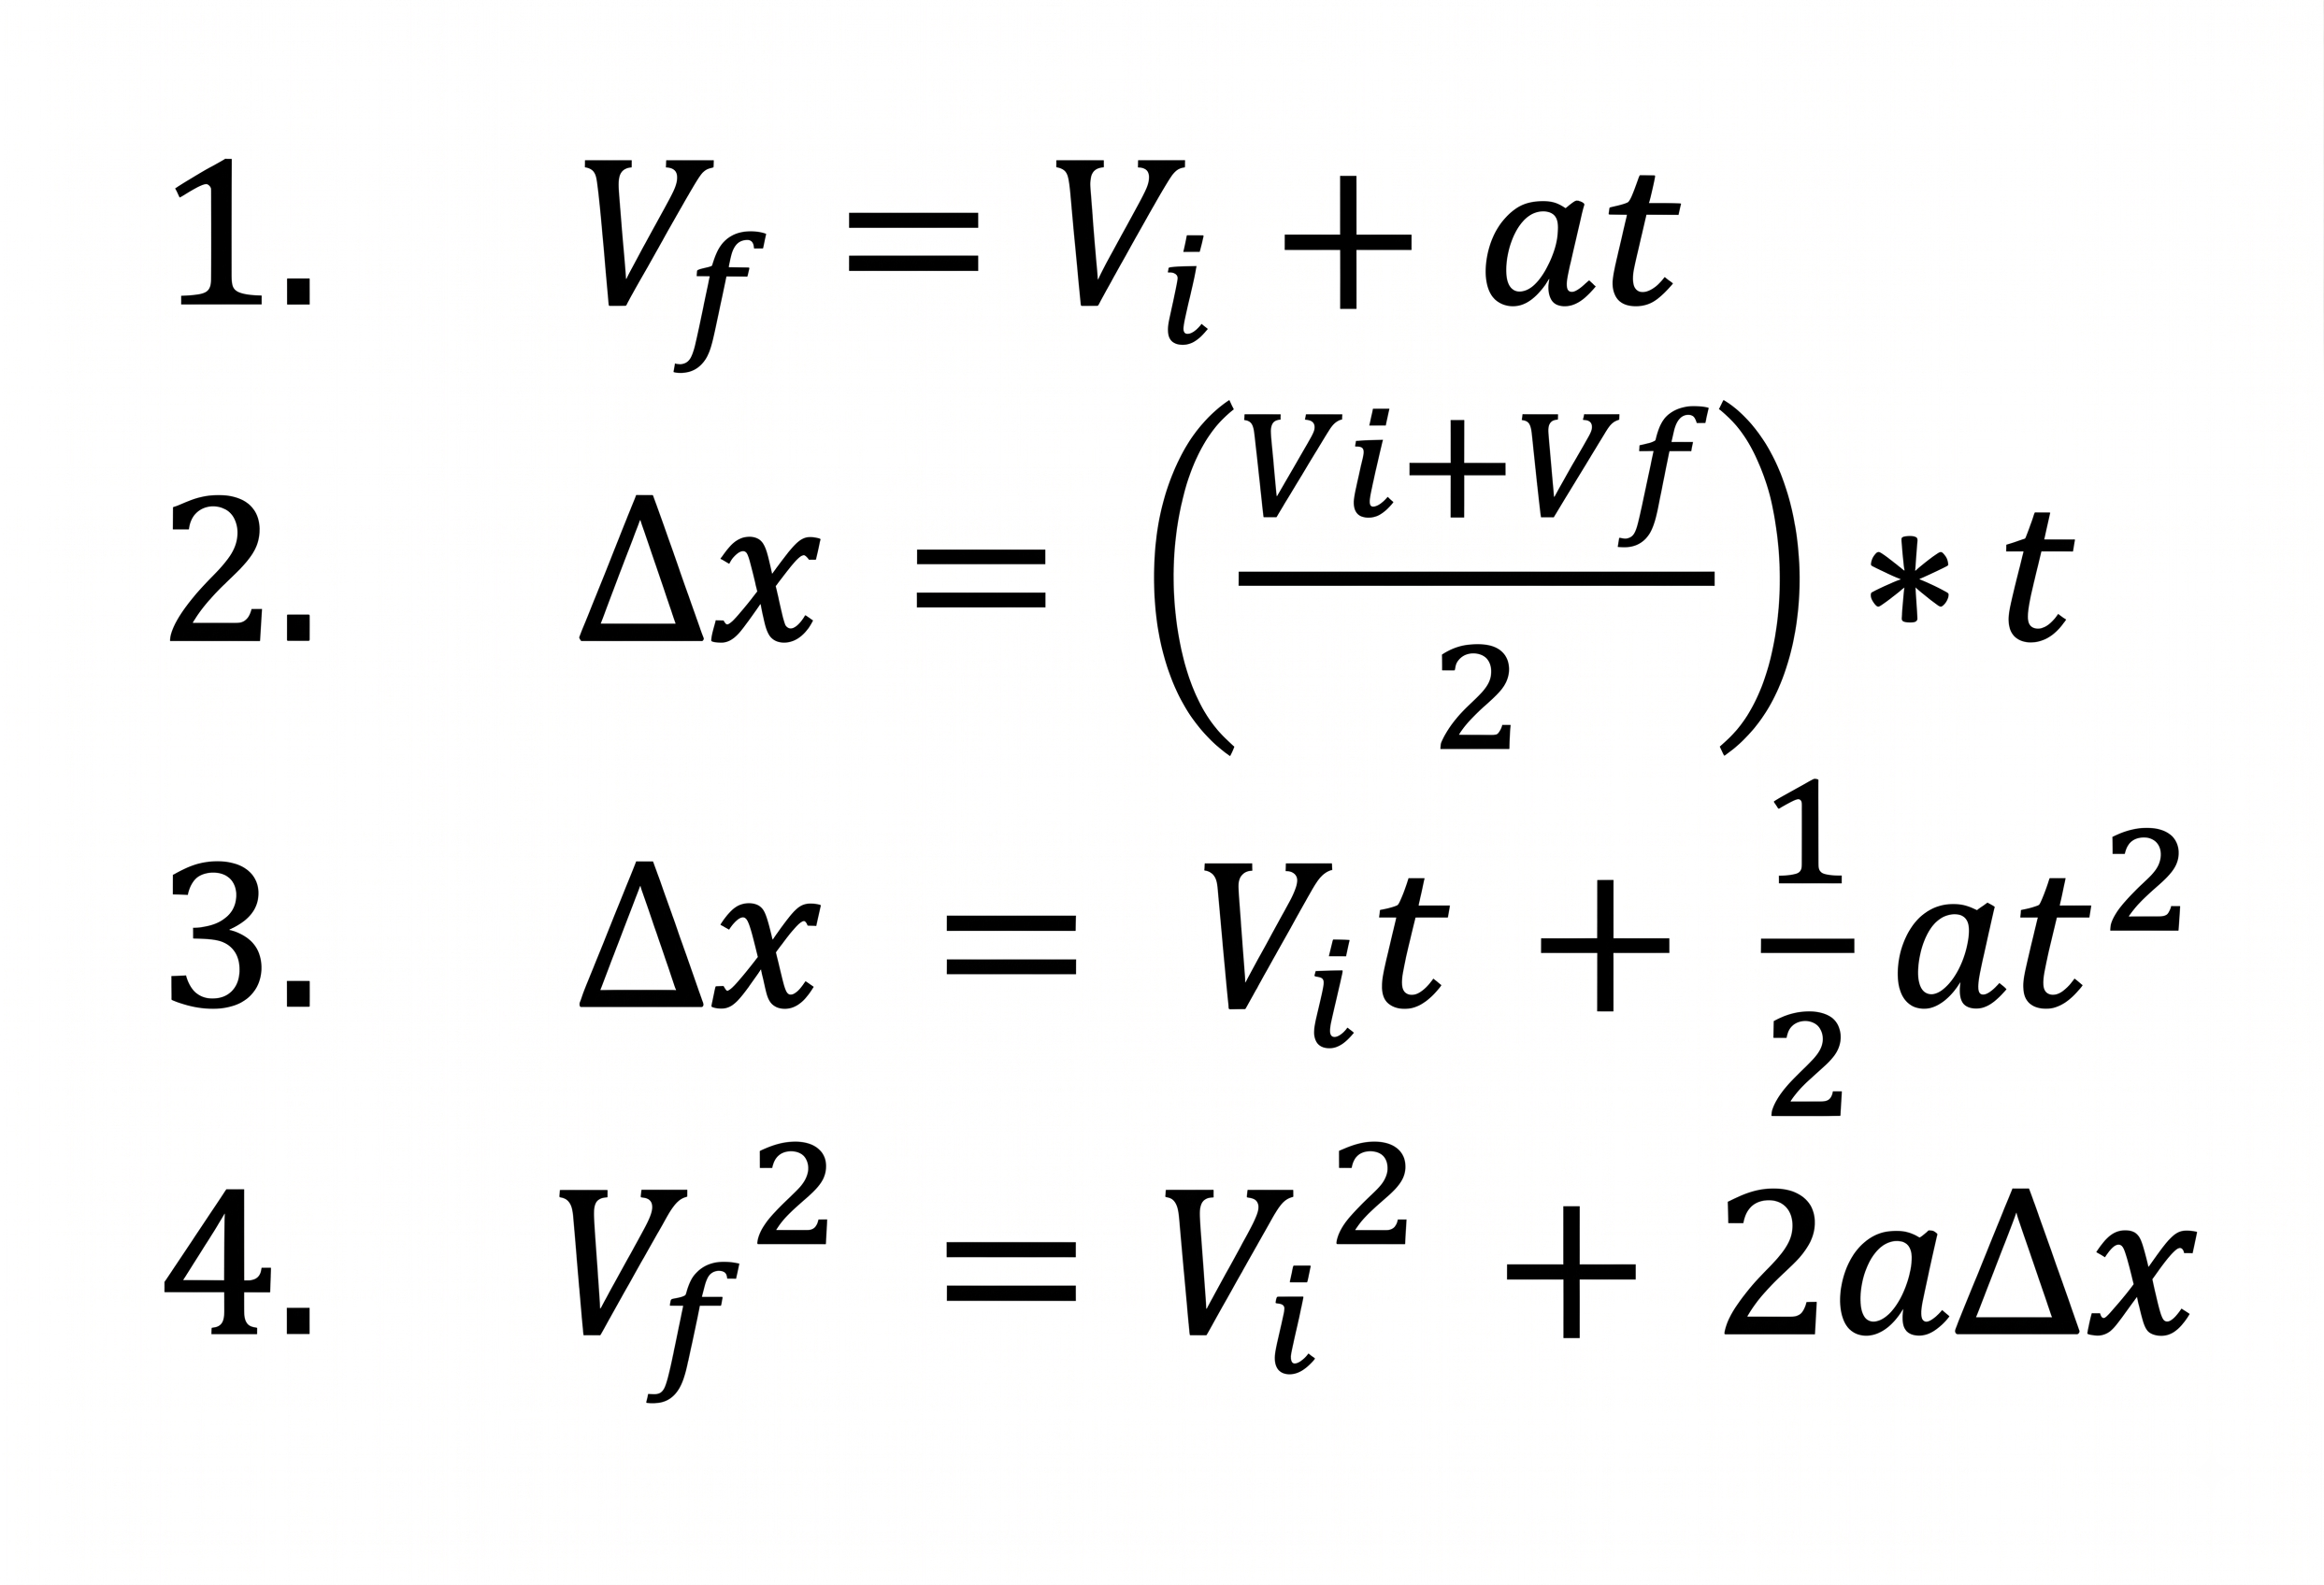
Equation 1 is virtually a re-statement of Newton’s second law, F = m a; Equation 2 is simply the Merton Rule. The derivation of these equations is well-documented in the literature.
Acceleration is the critical parameter. By simple algebraic manipulation from Newton’s second law, forces can be quantified independent of mass, as Ampere resolved, leaving only the mechanics of motion being of interest.
The modified equations are therefore as below left. However, there can be one further qualification to these equations. In many cases of accelerating or decelerating motions, either the initial or the final velocities are zero. Therefore, application of the four equations can be simplified to those below right.
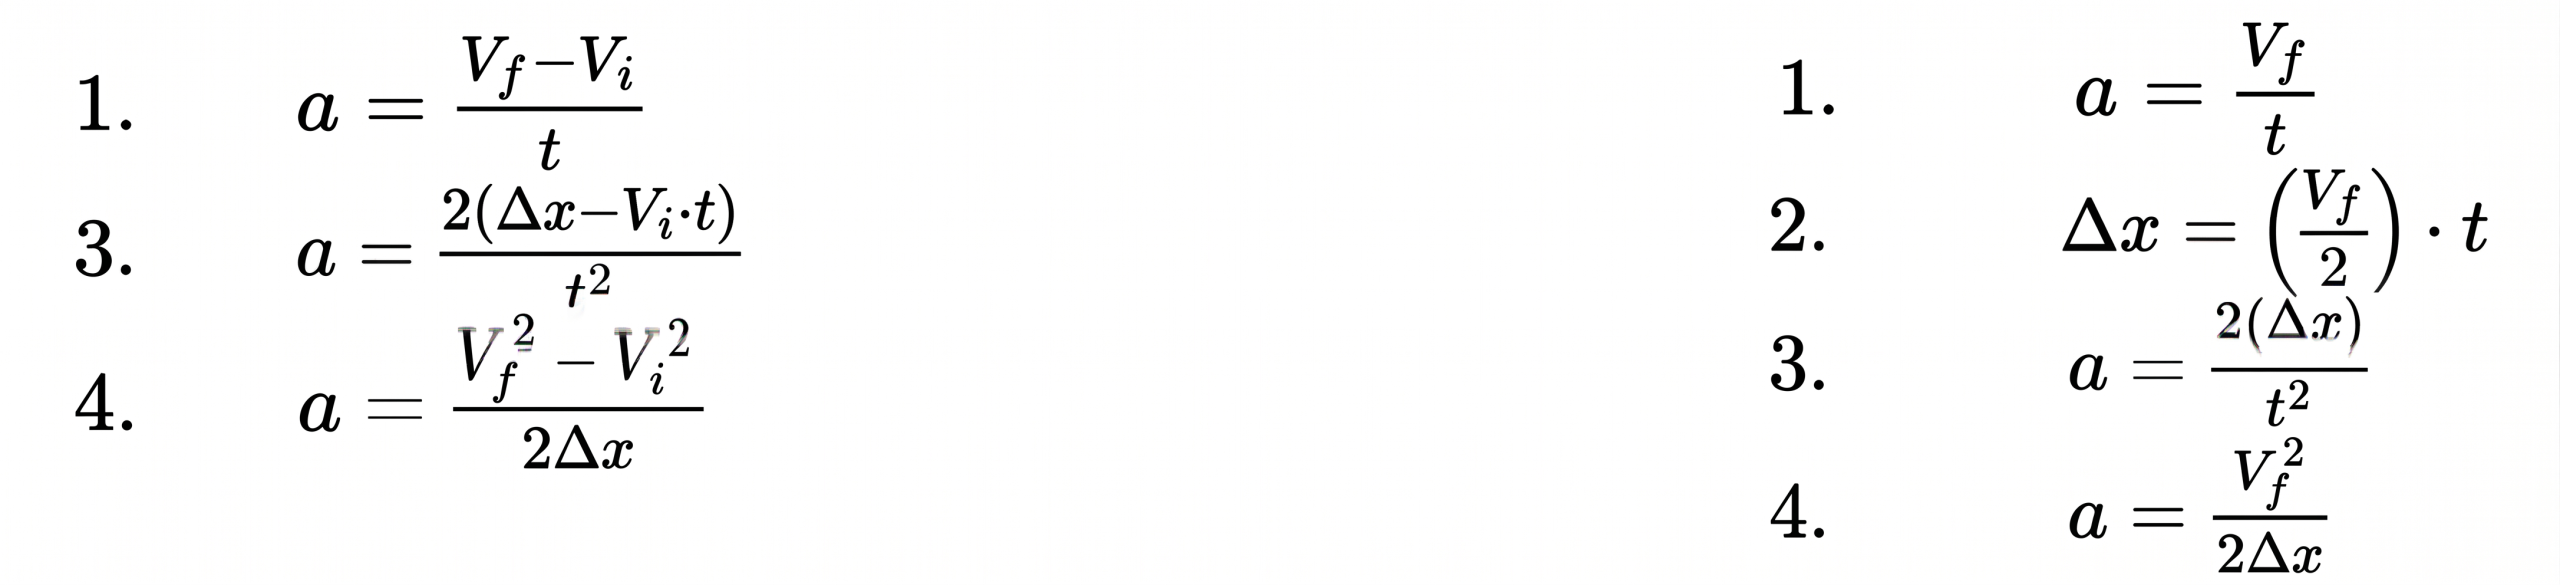
Acceleration is a measure of a change in speed. Acceleration happens when any object falls to the ground and is the measure of the change in speed between start and end. The force of gravity causes this fall, so, falling involves, as any motion does, a cause and an effect. Acceleration is the effect – the “how things move” – as opposed to gravitation, which in this case is the cause – “why things move”.
Confusion arises when “g” is used to define the on-earth gravitational constant of 9.81 m/s2 , but it has become a convenient reference point to compare acceleration levels and physically comprehend what a force of 1 g might feel like.
When subjected to freefall, an object’s falling velocity will increase a rate of 9.81 meters per second for every second of the fall until it reaches the ground. Acceleration due to gravity equates to 35 km per hour per second; by comparison, a Bathurst Gen3 Supercar that accelerates to 100 km per hour in 3.5 seconds reaches only 7.9 m/s2, or 28 km per hour per second.
Kinematics calculates acceleration in m/s2, but this article shows acceleration in terms of g units by dividing m/s2 units by 9.81.
READ: How the next generation of engineers is integrating safety into road design
The mechanical elements of motion
Even considering the intention of the owners of shopping centres and carparks to keep speeds in these areas low, speed restriction devices should be able to be traversed comfortably at the set limit. The principles of kinematics can be used to assess why the preponderance of Type 2 speed humps are so objectionable to the public.
Four separate stages or elements of motion can be identified in the interaction of a wheel passing over a road imperfection such as a speed hump. The Type 2 hump will be used as the example for illustration and background.
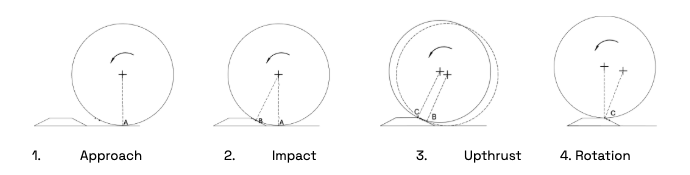
- Approach: The wheel is rotating without any impediment (as on an open road). Its only contact with any surface is the road at A.
- Impact: Suddenly it meets the ramp surface of a hump at its point of impact (POI), B. If it meets the solid edge of an object like a wheel stop or a piece of timber, or even a rut in the roadway, the effect is identical.
- Upthrust: Inertia and drive power will force the wheel to mount the remainder of the ramp until it reaches the top of the ramp at C.
- Rotation: At C the wheel completes its mounting of the full hump height. The lift in this rotation is the same height as the POI is above ground.
There are only two parameters that are critical to the passage of a wheel over an obstruction: the diameter of the wheel and the height of the point above road level of its contact with the obstruction.
Impact is the first, and can be the most important, element in the overall analysis of motion over humps. The first contact that a wheel makes with a speed hump is at its POI. It is not uncommon to believe that when an obstruction has a ramp or inclined surface, that the wheel rides the ramp from its absolute start. This is far from the truth.
The wheel’s circular arc will always form an “impact bridge” suspended above the join of the ramp and the ground. This Impact Bridge is the PG section of the triangle OPG pictured below. It is determined by trigonometry only from the diameter of the wheel and the height of its POI with the hump.
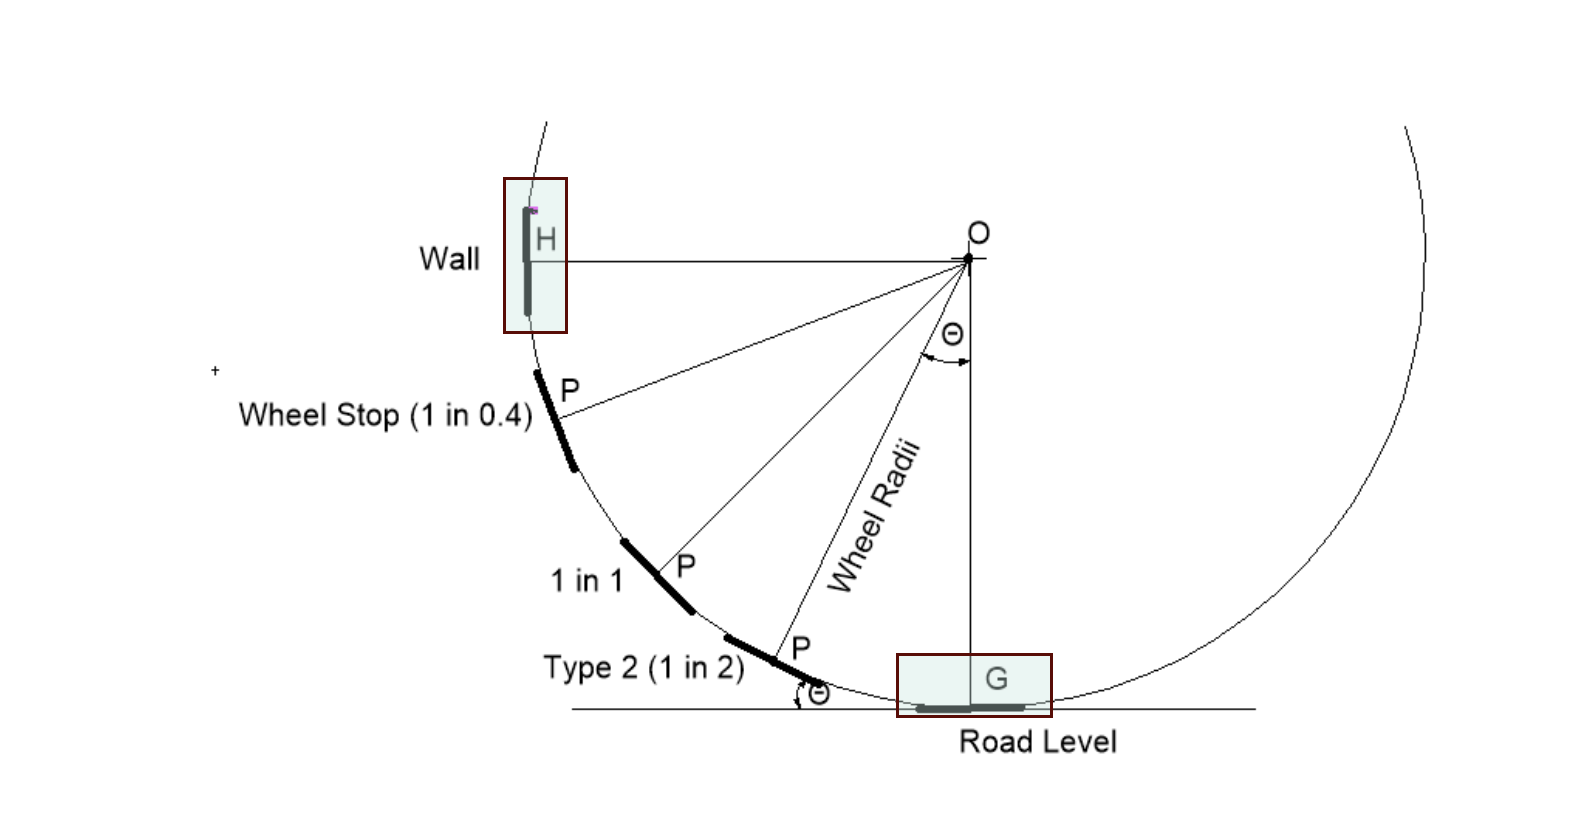
More importantly, this figure shows how the various POI of speed humps and wheel stops can be represented as slopes that are really tangents to a circle. Tangential geometry therefore becomes part of kinematics.
At the two case extremities H (wall) and G (no obstruction) the horizontal impact accelerations would be 100 per cent and zero per cent respectively. Anywhere else, at the P points, impact forces would be somewhere in between, which becomes the crux of any analysis.
Assuming that at the moment of impact, the wheel will momentarily deform and stop before moving on, the kinematic equation
a
=
Vf2
2Δx
can be applied. At a speed of 3.3 km per hour and a deformation or stopping distance of 10 mm, the decelerations for the two extreme cases at H and G become 4.3 g and 0 g respectively.
The somewhere-in-between case can be analysed in terms of its impact bridge. In most cases wheel diameters can be considered constant, as in this analysis, so the important parameter becomes the POI.
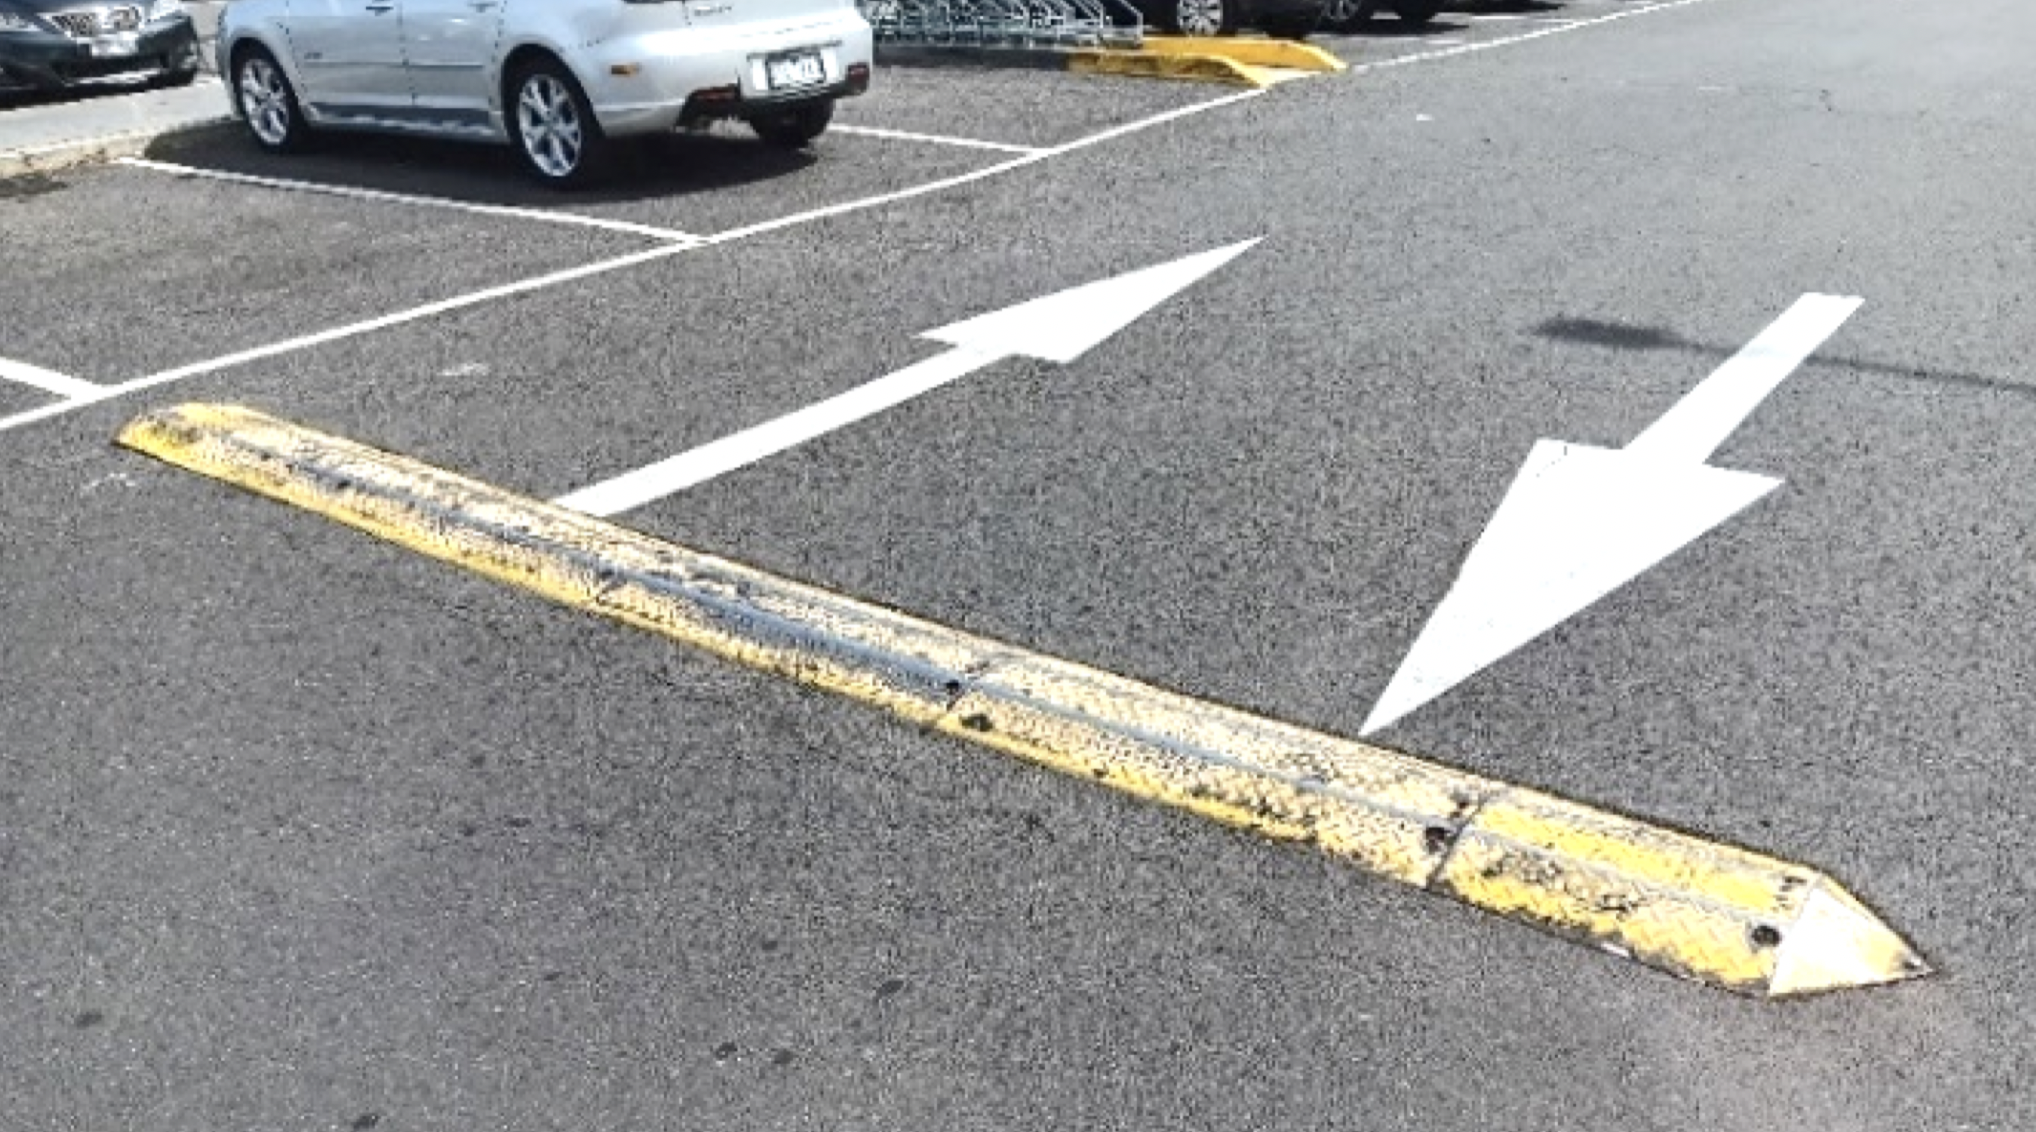
Practical evidence of this impact bridge can be found with humps in shopping centre carparks. After being in-situ for more than 10 years, a 50 mm high metal Type 2 hump, shown below, shows most wear on its top edges. The wear only starts 70 per cent of the distance up its ramp, at its POI, proving the impact bridge concept.
The POI is the single most important parameter in the mechanics of speed humps. Its role cannot be stressed enough, because the magnitude of the initial impact at the POI could be the real cause of the universal public hatred for speed humps.
In mechanical terms, the POI is actually a point. When billiard balls hit each other, they meet at only a point on their surfaces. The vector direction of the moving ball and the relative position of the hit on the stationary ball – their POI – determines the vector directions of both balls after the hit.
Similarly, when a car wheel hits an obstruction on a road surface, the ground is immovable, so the wheel must eventually deflect upwards to ride over the speed hump or road obstruction. But before the wheel begins to rise, there are immediate forces in play which hitherto appear not to be recognised mechanically.
A more useful way to understand the actual mechanics of the forces involved is to treat the wheel as if it were a solid disc moving at whatever speed along the road surface without friction. As soon as impact is made with the POI, the obstruction sends an impact force along the radius of the disc to the wheel–disc axle. This impact force has both horizontal and vertical vectors. It is these vectors to which Newton’s third law of equal and opposite reactions can be applied.
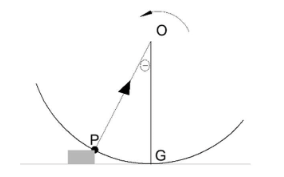
The above figure depicts the POI at P, in its absolute simplicity. It is a point in three-dimensional space above ground level and offset to its wheel’s vertical radius by a subtended angle, ϴ, which is essentially the measure of the impact bridge.
In this diagram the POI is represented by the rectangular edge of a beam of wood or metal. It matters not whether the POI point is a point on a slope or on any edge. The point itself is the crux. At the POI the vectors will be trigonometric rations of cosine ϴ for horizontal and sin ϴ for vertical.
As the key parameter in the mechanics of speed humps, finding the POI is paramount. No evaluation can proceed without it, and though its location is not always given, it can always be calculated.
In these calculations POI, is shown as “p”, slope as “s”, wheel diameter as “d” and angle as “ϴ”.
Starting from p, useful relationships between these parameters are:
- cos ϴ = (1 – 2p/d) cos ϴ = s /√(s2 + 1) s = cos ϴ /√(1 – cos2ϴ)
READ: Why durability testing is the true gatekeeper of green construction
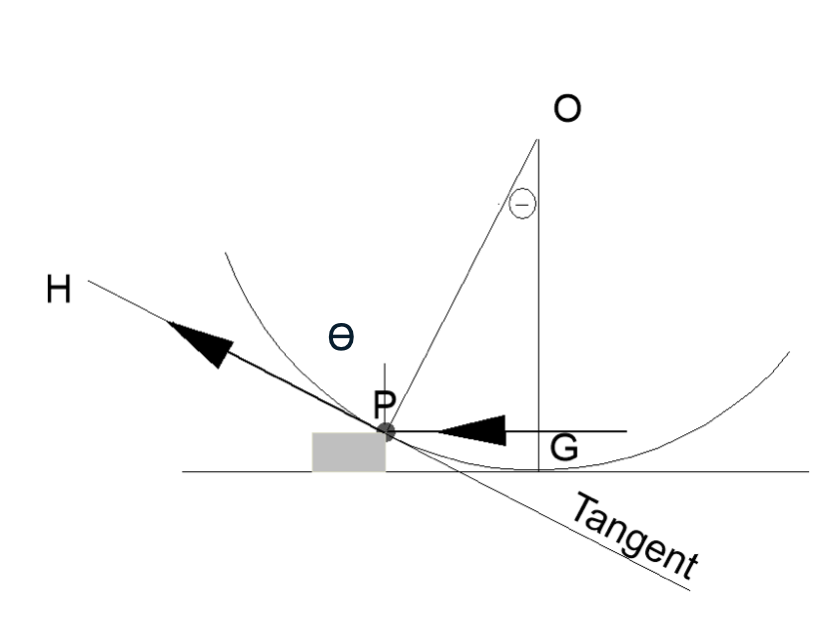
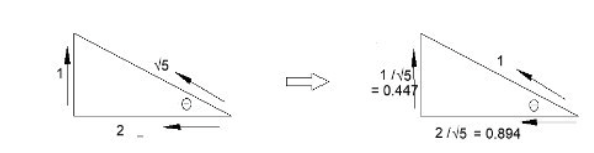
- For the Type 2 hump, Vi = 3.3 kph = 0.917 m/s Vf = 0.917*cos ϴ = 0.917*2/√5 = 0.820 m/s.
- The distance through which this deceleration takes place is effectively the “squash” of the car tyre.
- The “squash” of the subject car tyre at rest was 10 mm and this was used for the squash on impact too.
- Acceleration – or, in this case, deceleration – was calculated to 8.42 m/s2 = 0.86 g.
Impact acceleration levels are highly sensitive to the deformation or “squash” of a wheel’s tyre. In the absence of proven data, 100 mm was used and deemed to not change with speed at impact. If squash varied with speed and, for example, was halved, the acceleration level above would double to 1.72 g. This horizontal impact motion does not appear to have been considered separately in the work cited in the Austroads Report and further research would seem justifiable and desirable.
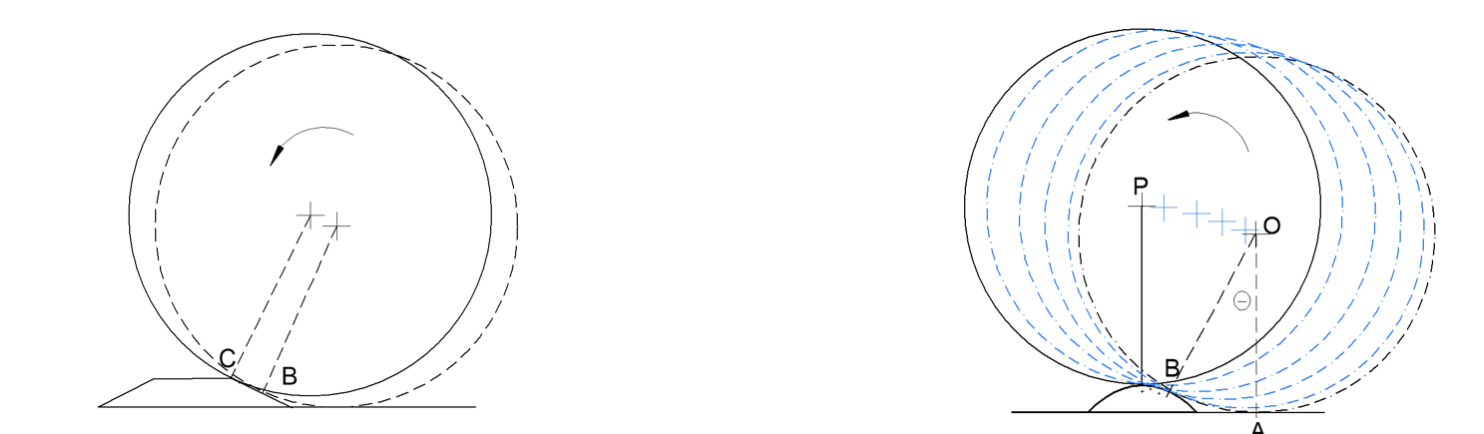
The upthrust motion, however, is slightly different when considering the sectional geometric surface of the hump.
Returning to the analogy of the wheel as a frictionless disc, for trapezoidal humps like the Type 2 one, the slope of the ramp section causes the wheel to move from B to the top edge of the ramp at C as shown above.
(a). This movement is in a straight line and presumably at the same speed along the ramp as the horizontal approach speed. Considering this to be a separate go/stop motion event, the kinematic equation of
a
=
Vf2
2Δx
- For the Type 2 ramp, the initial vertical velocity is 0.917*sin ϴ = 0.410 m/s.
- Vertically, the wheel is raised 50 – POI = 15.6 mm.
- The upthrust deceleration is therefore = 5.39 m/s2 = 0.55 g.
If the Type 2 hump height was increased to a height of 75 mm by extending the one in two ramp length, the upthrust acceleration would be 2.07 m/s2 = 0.21 g. Kinematics therefore indicates that increasing heights of Type 2 humps, without changing the ramp slope, does nothing to further quell speed but will only help to alleviate discomfort for vehicle occupants.
For chordal humps where the cross-section of the ramp is the arc of a circle, as in the Watts profile humps, the movement trace of a wheel’s axle is no longer a straight line but an elliptical arc.
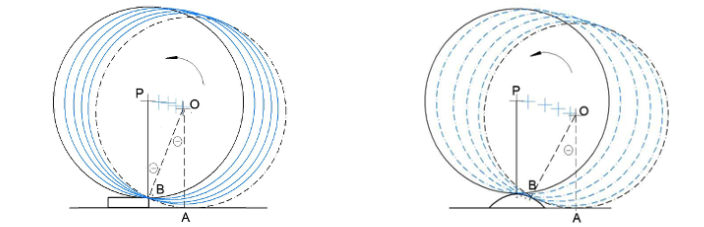
Similarly, when the road obstruction is a rectangular beam of wood or the rim of a man-hole cover, as seen at right in the diagram above, the upthrust for the wheel to rollover the point of contact requires it to be considered as a form of rotation motion.
READ: The 84-year-old engineer behind some of Victoria’s major roads
High rotation
The final rotation motion occurs at the top of the Type 2 ramp or at the POI of any other road obstruction.
When considering the final rotation motion of a Type 2 speed hump, it is necessary to include all three variations of the cross-sectional profile of the hump: trapezoidal, chordal or rectangular. In the figure below, each variation is shown to scale, each having the same POI. Each variation is directly equivalent to each other. The chordal and trapezoidal variations have the same footprint and same height.

In the previous section, kinematic equations were used to calculate the upward elevation of a wheel, even though the path of the wheel’s axle was the locus of a sloping straight line. That same logic or principle is now used here in the rotation motion.
For each case, the transitional motion from start A to end at B can be shown diagrammatically by the various stage circles and their axis points.
The only difference here compared to the upthrust logic is that a plot of the wheel’s axles no longer forms a straight line but is now an elliptical arc; the end result is still an elevated wheel.
The kinematic accelerations are shown in the table below.
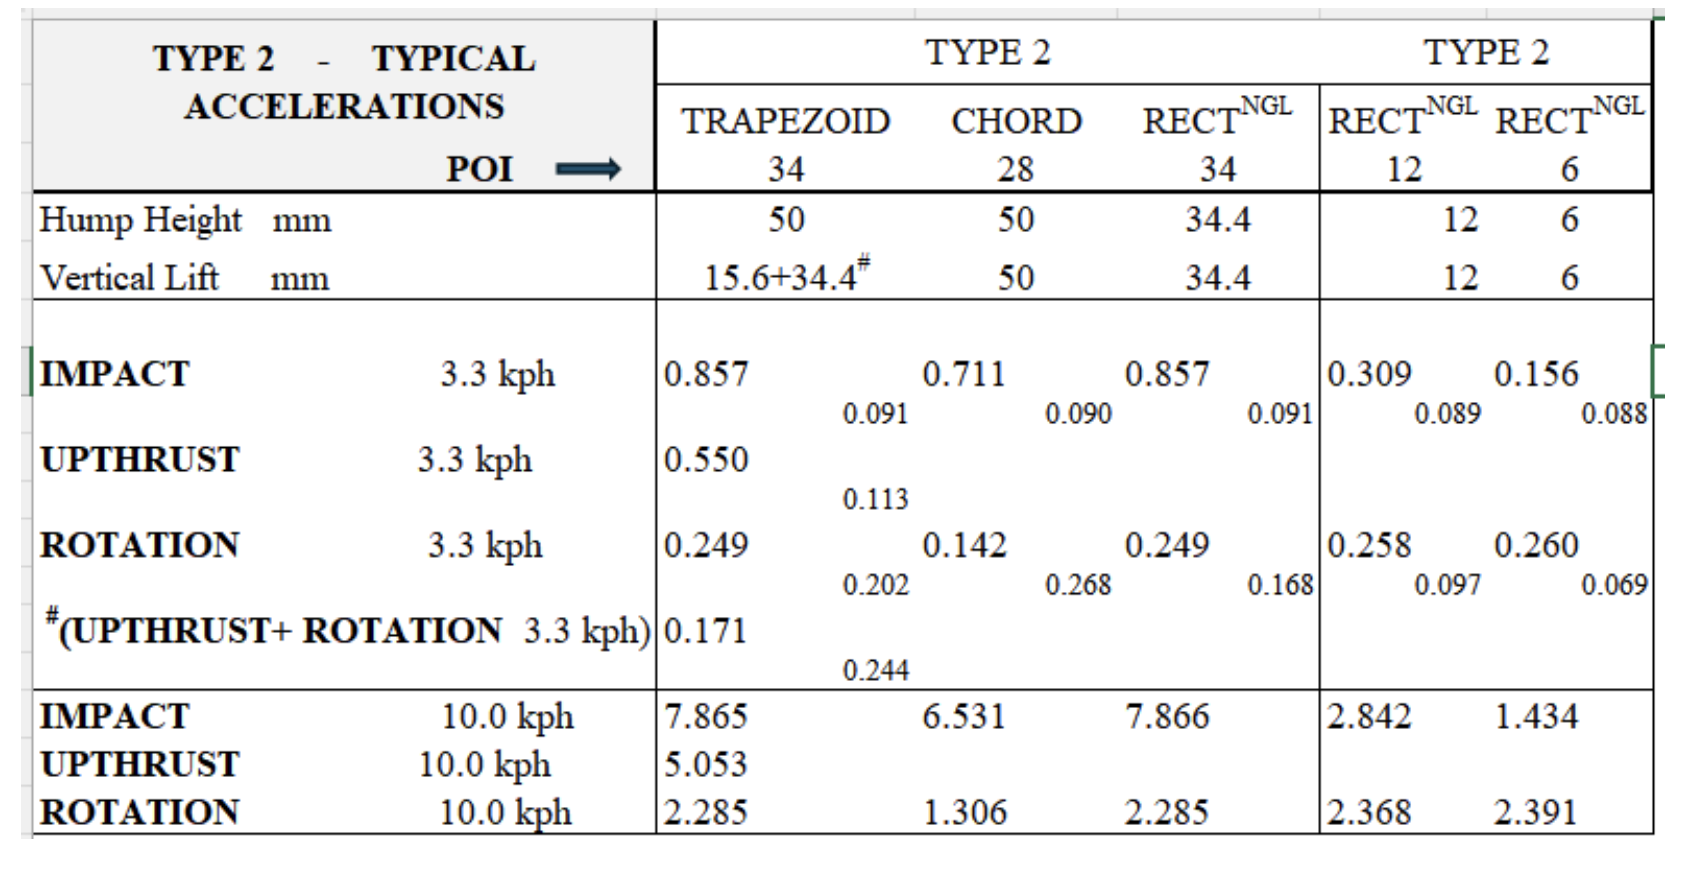
Following the optimistic “design” criterion of 0.4 g, the values for rotation would be acceptable at “conventional” speeds in carparks. Upthrust could be acceptable, but impact is certainly not. However, the significance of this comparison table is that a replacement of the Type 2 hump with a rectangular beam of much lower height could achieve a satisfactory level of comfort for vehicle passengers.
READ: From landfill to roads: Circular economy drives innovation in trench backfilling
A smoother ride
The following conclusions can be immediately drawn from this analysis:
- Impact element is critical and further field measurements should be seriously considered.
- Type 2 humps could be replaced by a beam of wood of lower height.
- Chordal humps with the same footprint exhibit slightly less discomfort by offering an equivalent but lower POI.
- Speed is critical, because acceleration varies by the square of the speed. If humps were to be designed at carpark limit speed, the 3.3x speed at 10 km per hour produces nine times the acceleration, in the region of g experienced by dragster competitors. Even a doubling of speed produces four times the force.
- Rotation accelerations, unexpectedly, do not appear to vary with POI.
The results reinforce the pain and discomfort experienced by the public in shopping centre carparks. The Type 2 “standard” at this analysis’s design speed of 3.3 km per hour meets criteria for the rotation element but not for the impact criterion.
Speed is shown conclusively as the major contributor to discomfort. Discomfort is a highly desirable factor for curbing speed at the speed hump, but it may not be enough by itself. Is a factor of nine between comfort at “conventional” design speed and discomfort at a park-imposed limit speed sufficient?
By assessing the mechanics of the motions and determining feasible scientific design criteria for achieving a “comfort” level, this analysis examined the discomfort experienced by vehicle occupants when traversing speed humps. The fundamental concepts of “impact bridge” and “point of impact”, POI, have been introduced as the key parameters into this and any study into road obstructions.
The choice of a “design” acceleration value for passenger comfort, while curbing speed remains a vexed question for public and private authorities. The adoption of kinematics can assist by providing the necessary computational link between comfort, speed, height and slope.
The Type 2 Speed Hump of AS/NZS 2890.1 became the target of this analysis and was critically examined. Of the three mechanical elements, impact, upthrust and rotation, impact was found to be the most important. There is a case for earnest deliberation by Standard Committee CE001 in modifying their standard for carpark humps.
Geoff’ Walton MIEAust’s qualifications of BE (Met & Chem) and, later, M.Admin, have been instrumental in a process engineering career spanning nearly 50 years. Since 1990, Geoff has been consulting in process systems improvement, solving and optimising problems in both physical and management processes.
Explore Engineers Australia’s submission to the National Road Safety Strategy